Projects
Current developments and past milestones.
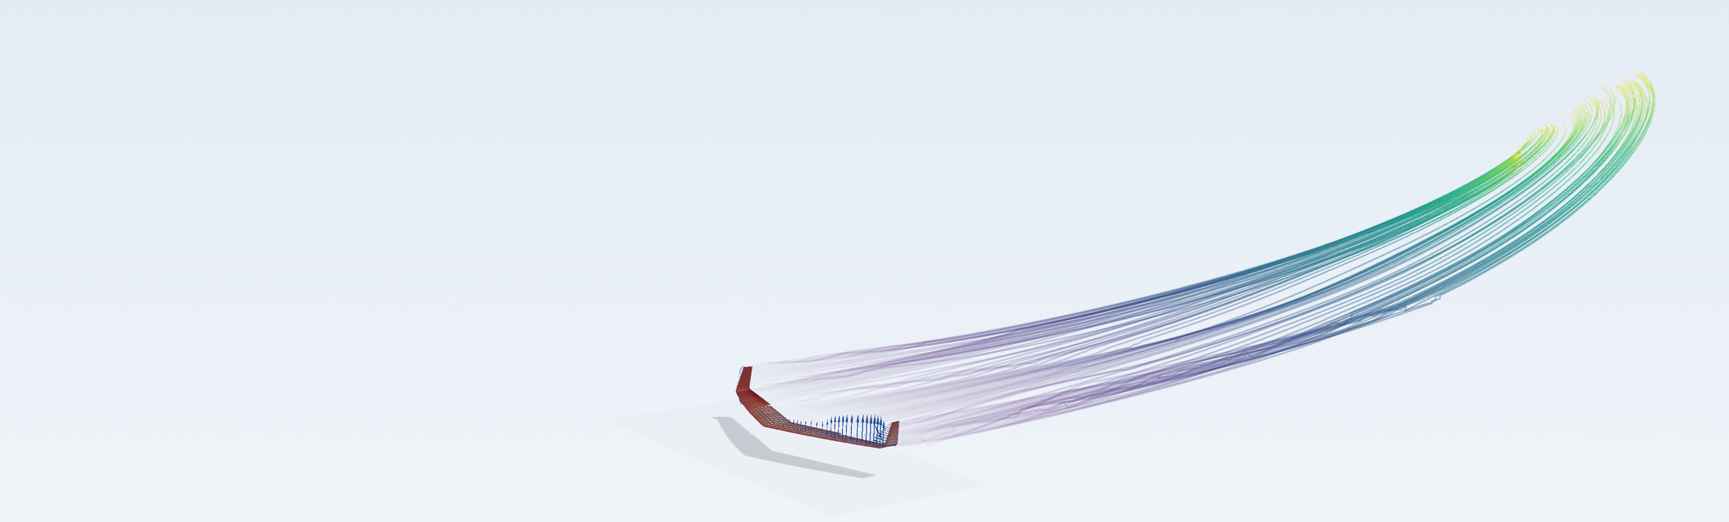
New Projects at FLYATIVE
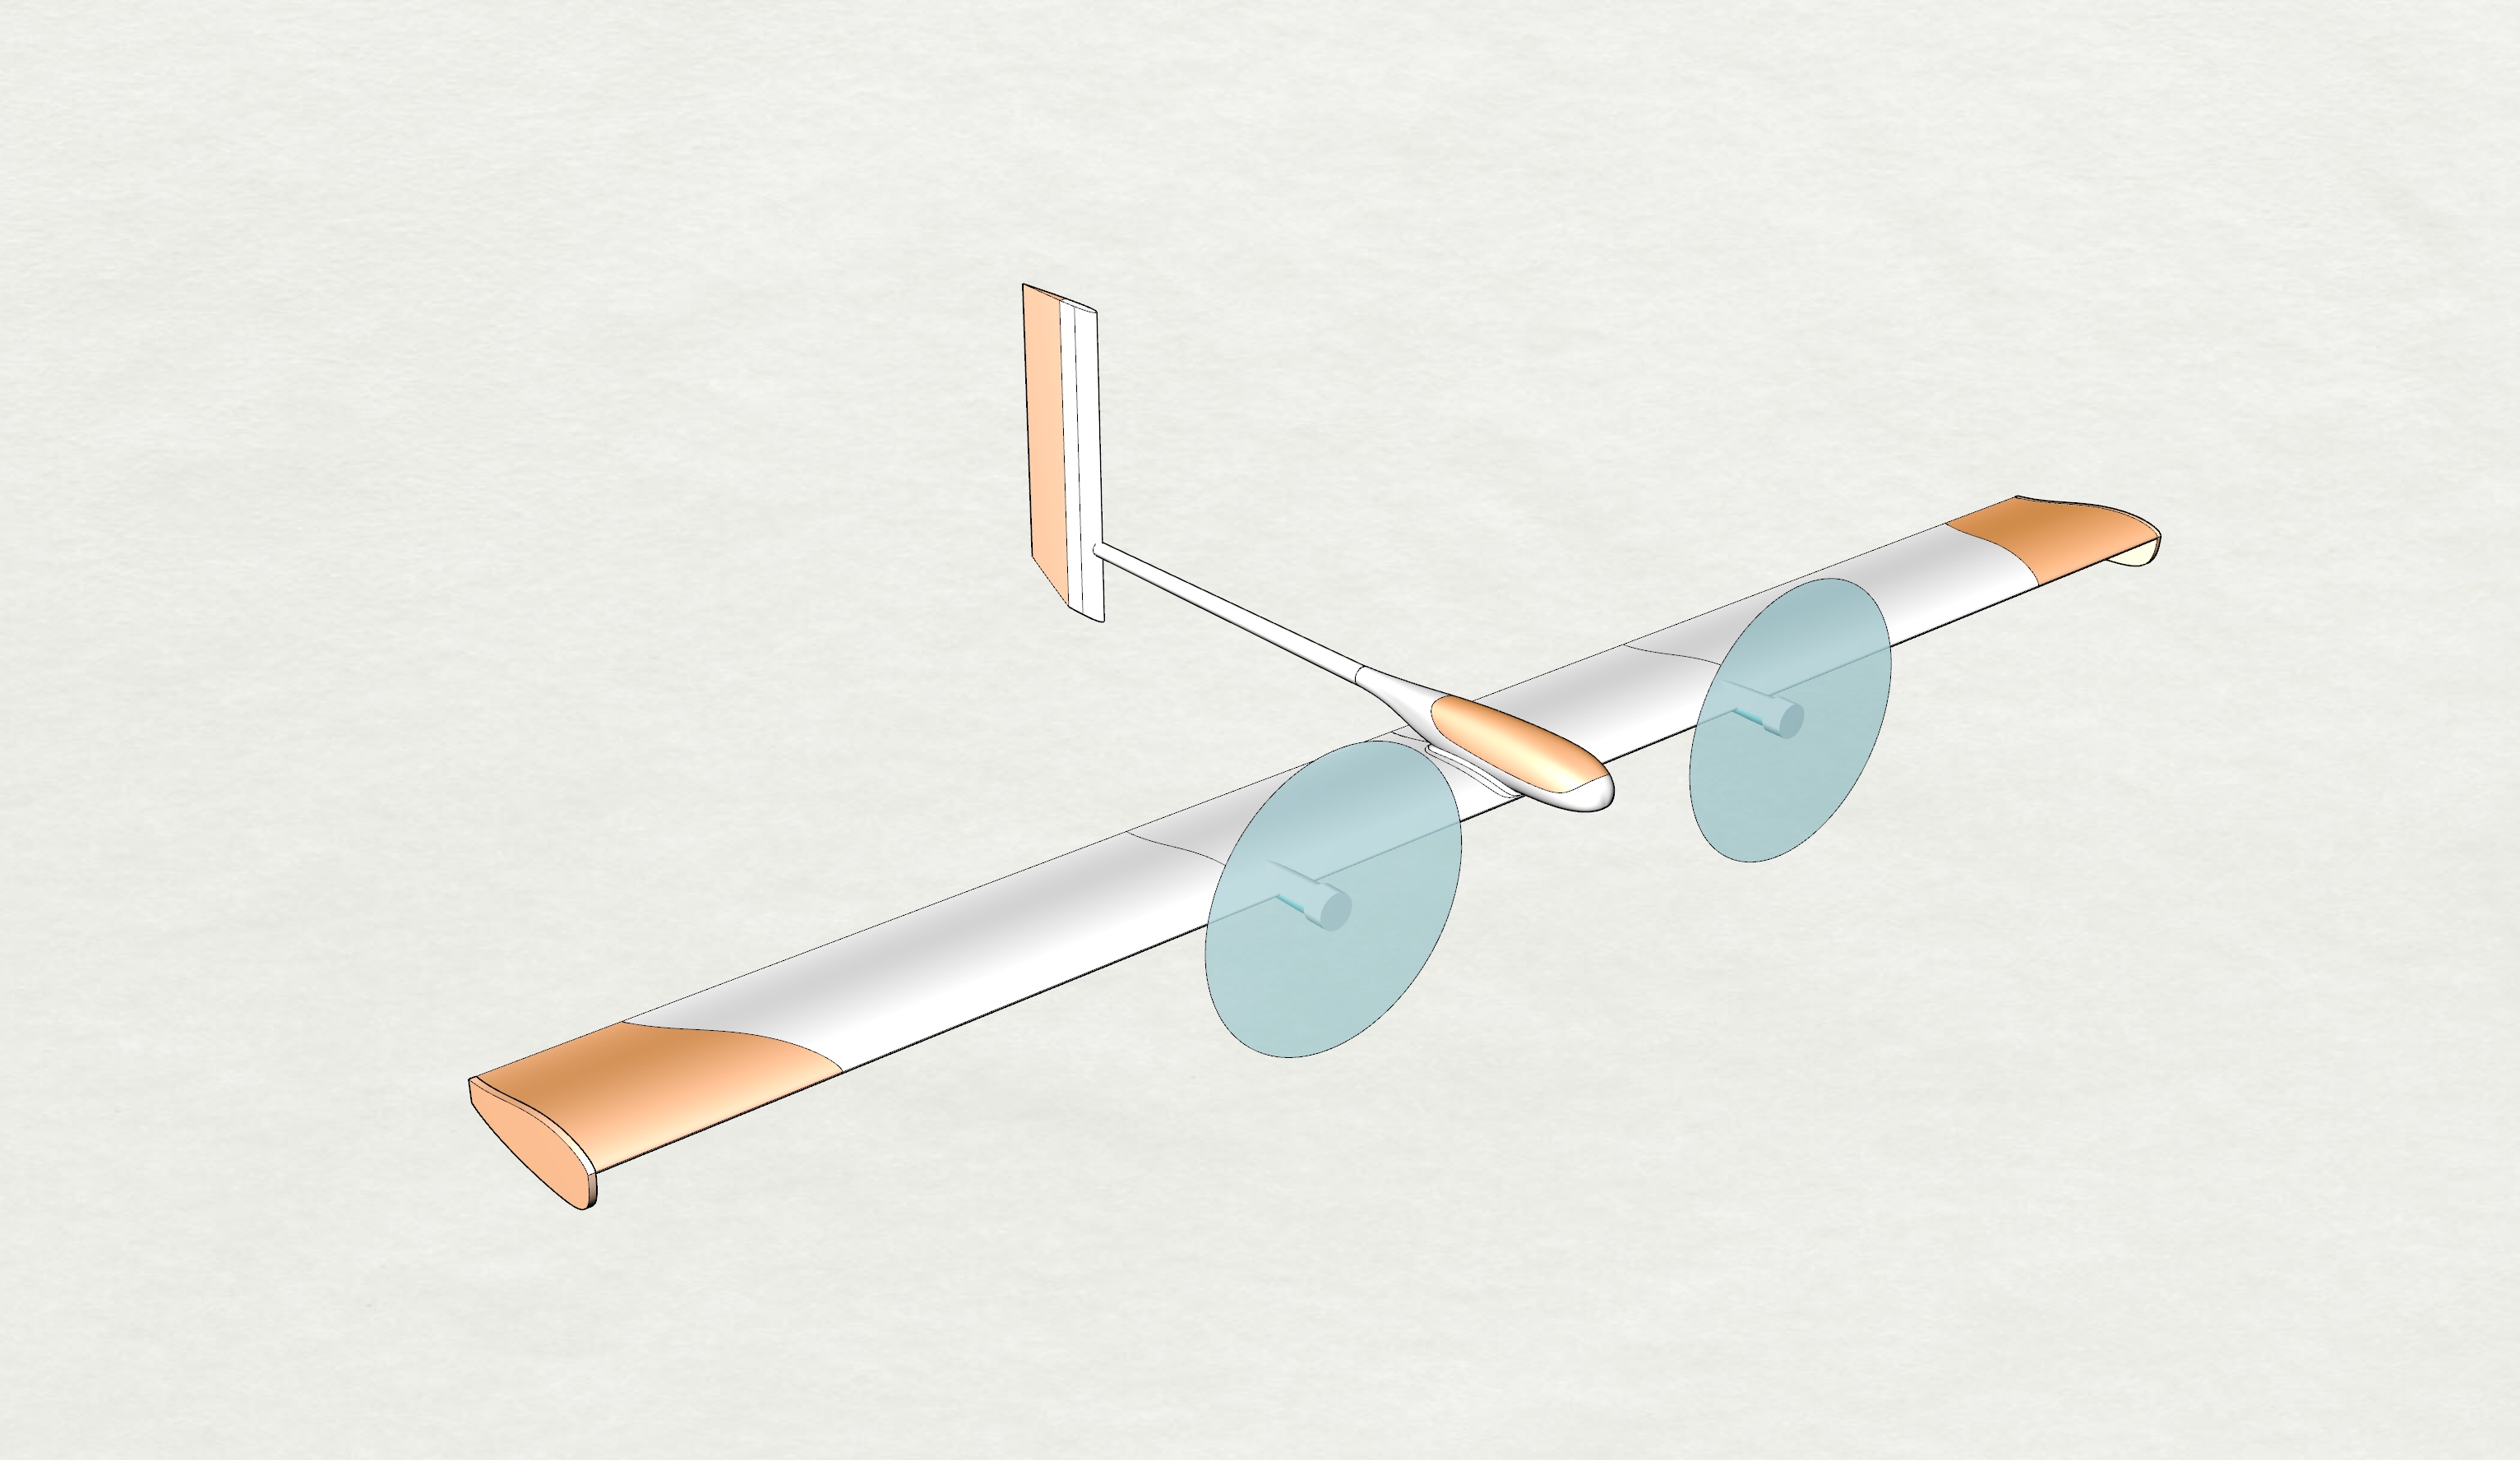
Next-Gen Composite eVTOL Wings
Support in Engineering next-generation composite eVTOL aircraft for autonomous Airborne Wind Energy: early-stage concept evaluation and support for rapid prototyping.
Completed Projects – Featured List
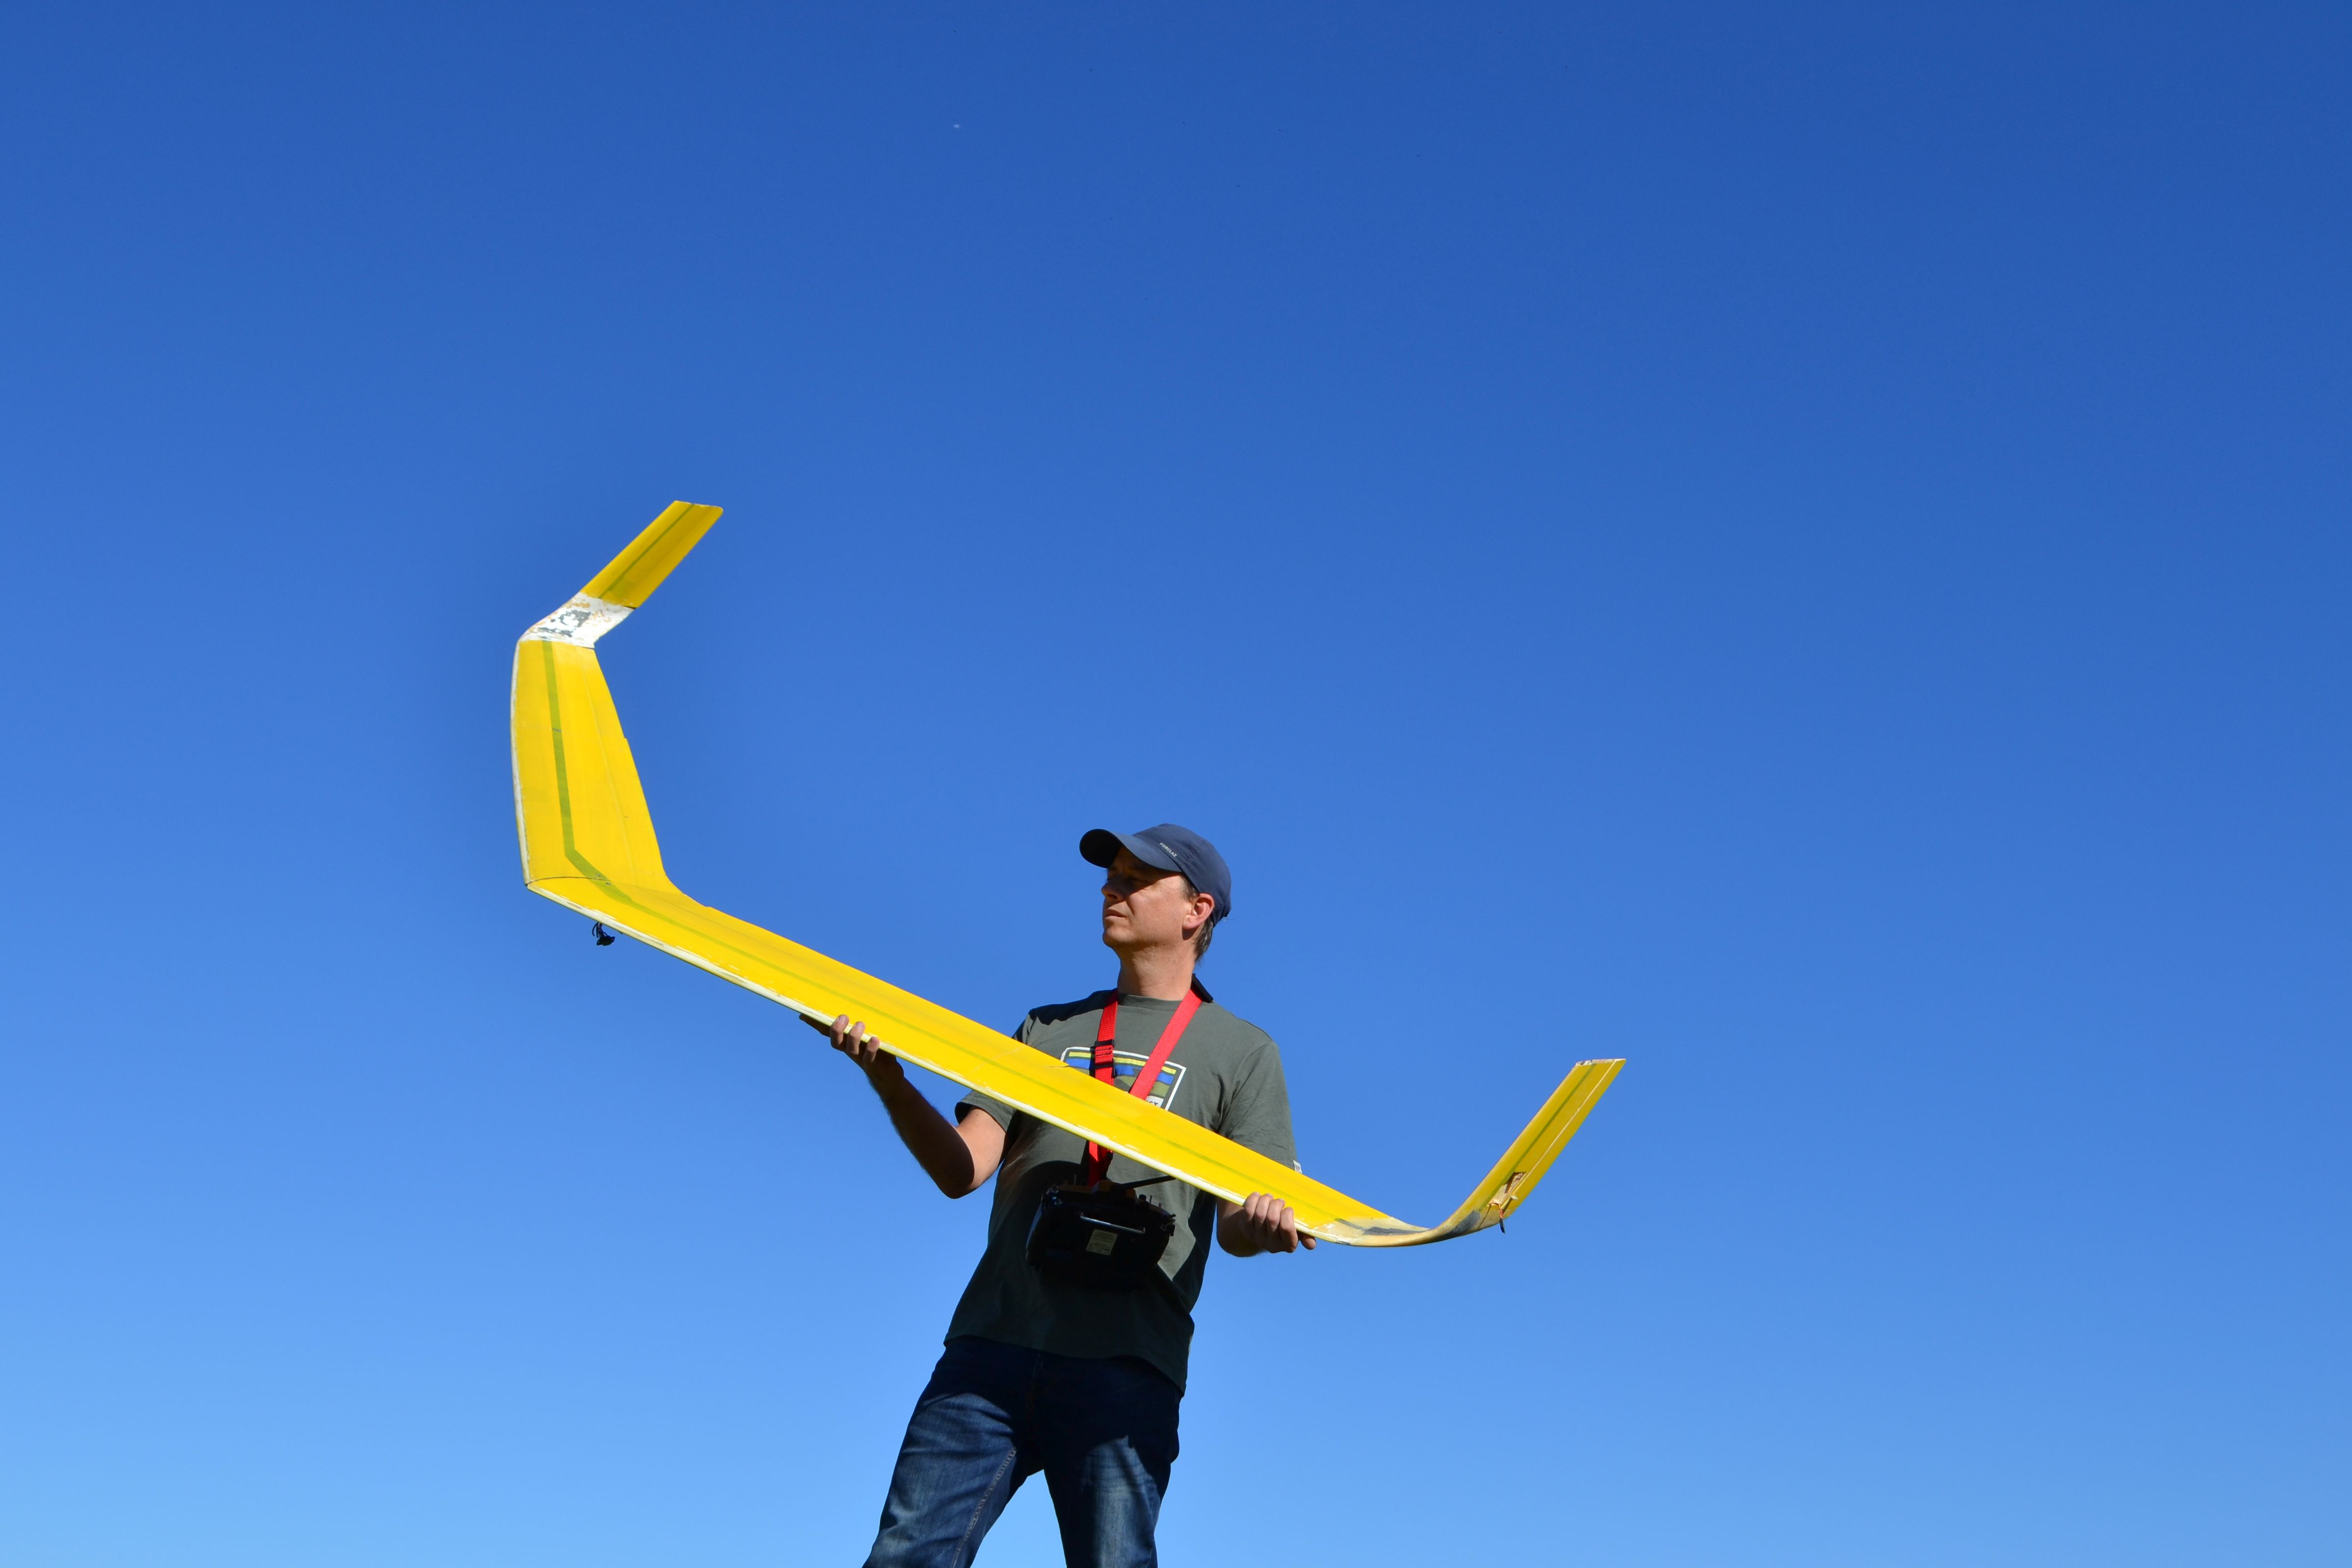
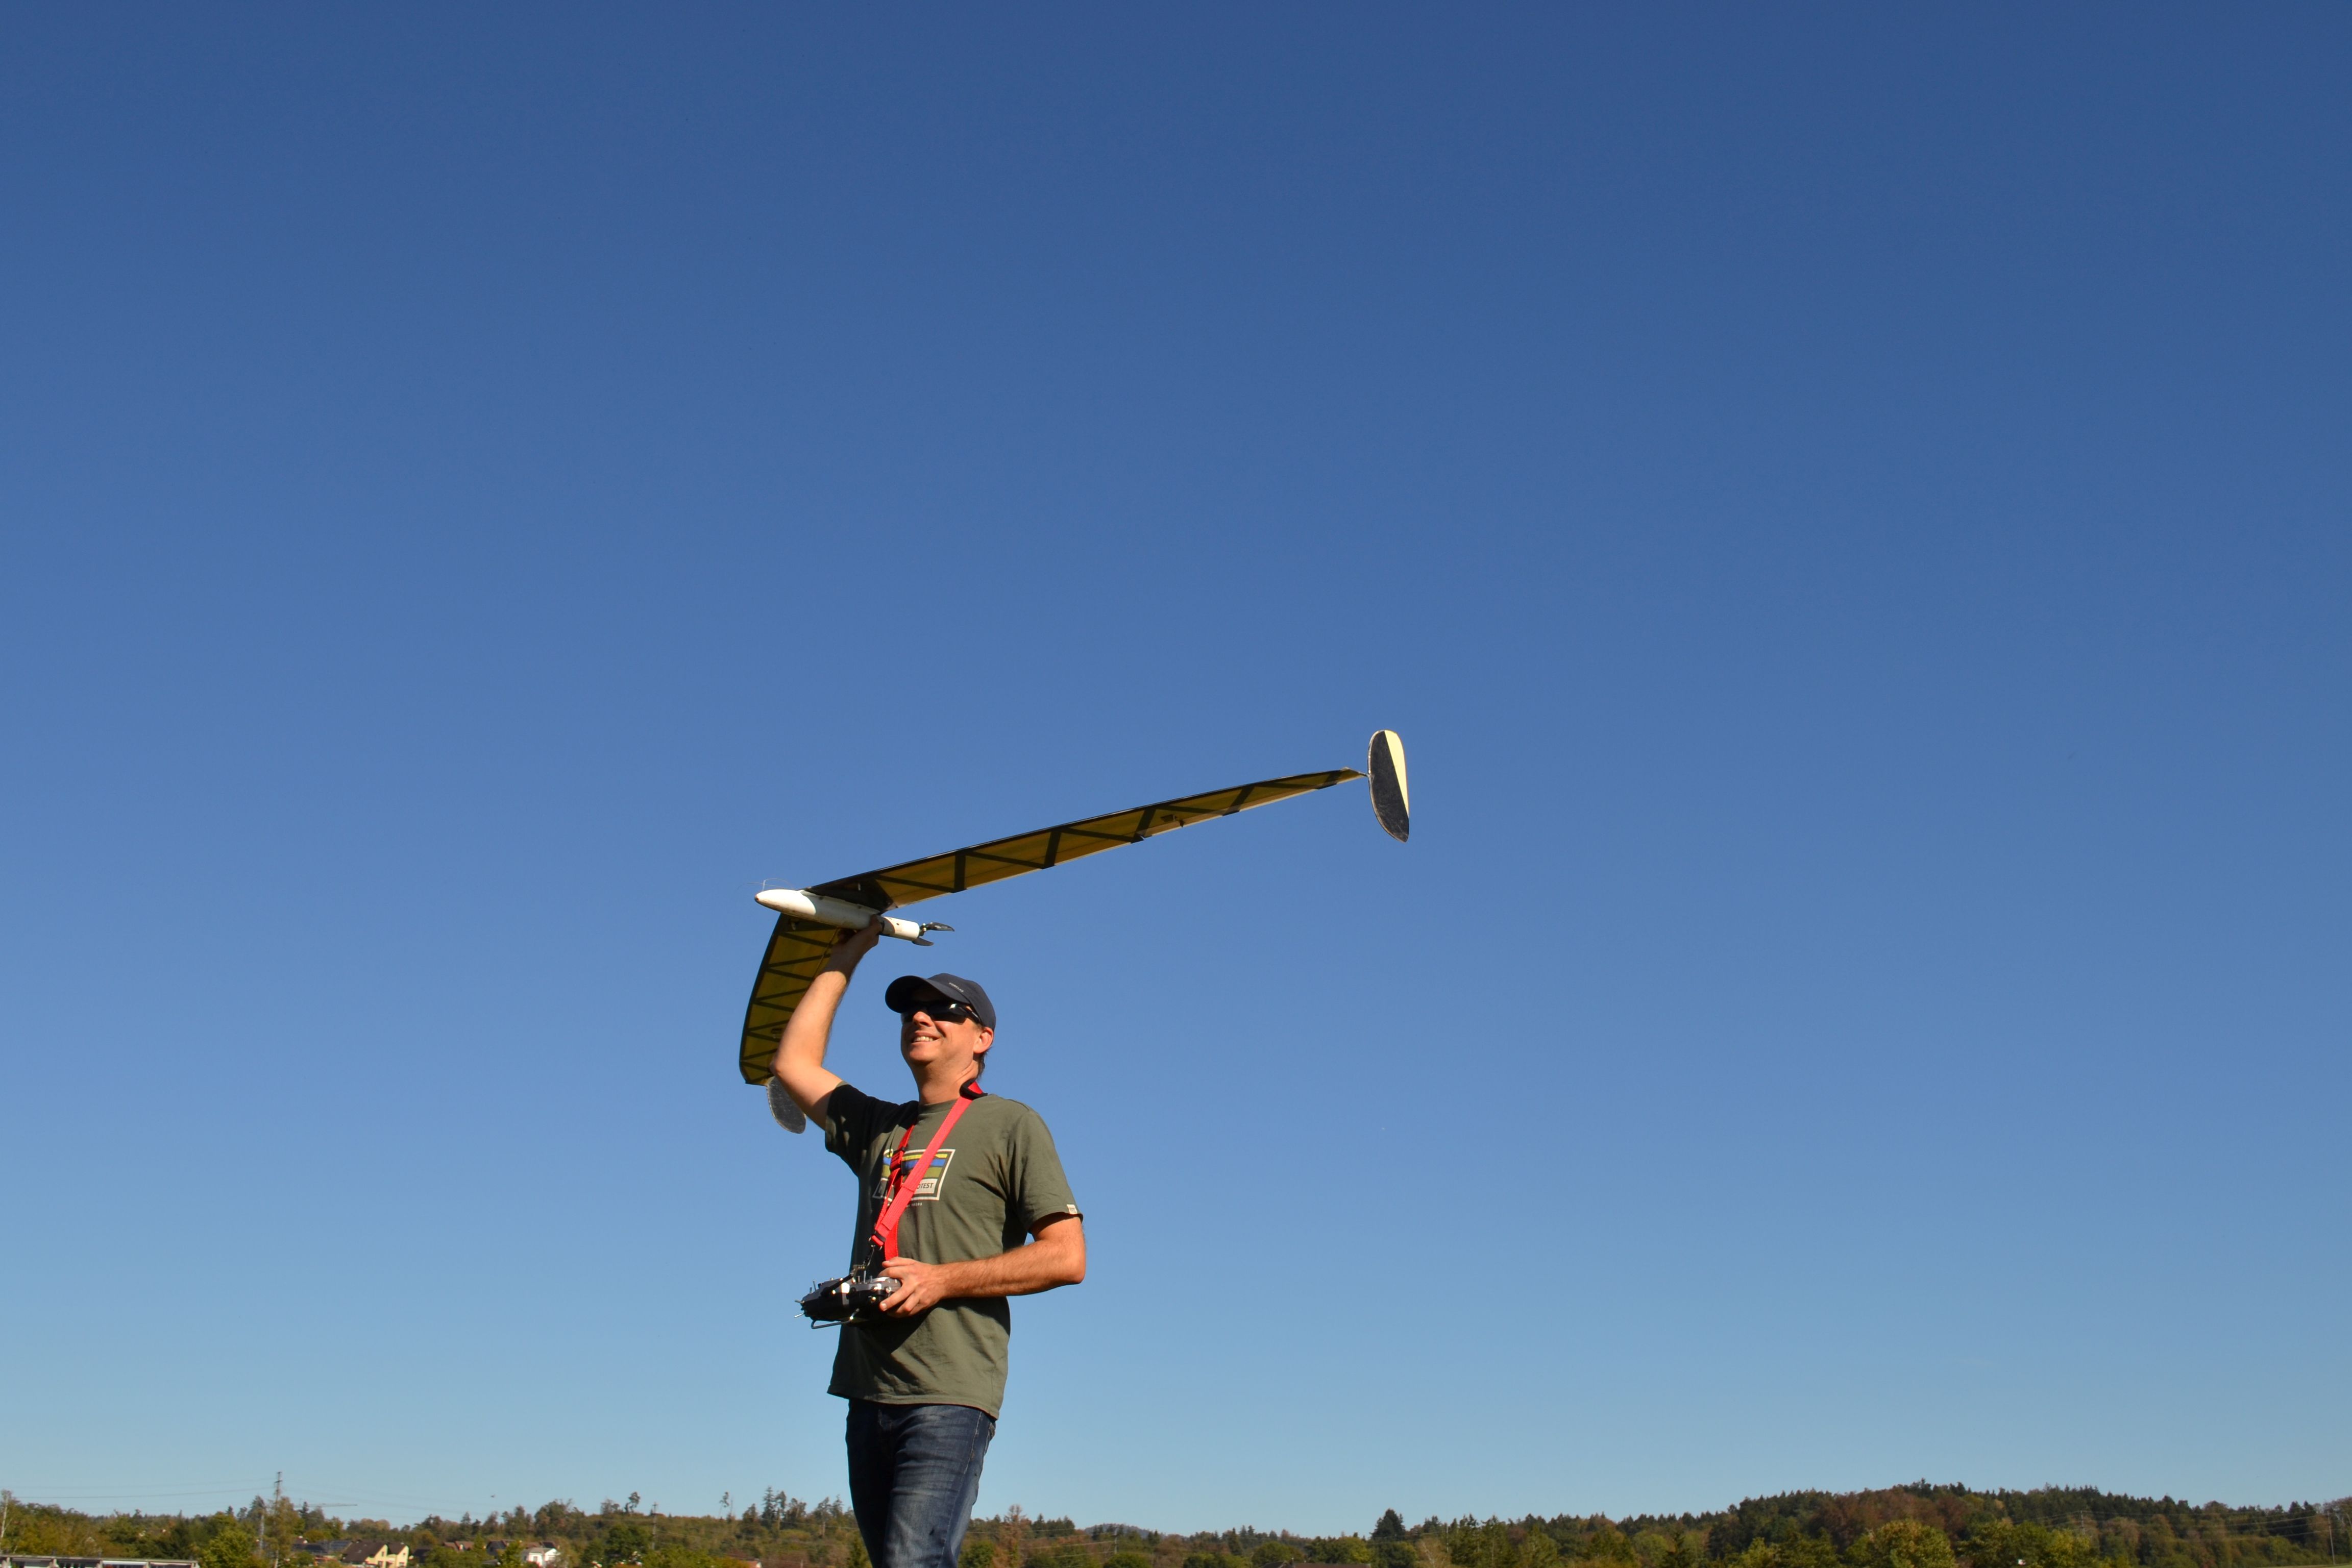
Custom Toolchains & Experimental Aircraft
In-house fabrication of composite airframes paired with custom aerodynamic shape optimization toolchains. Designed with FLYATIVE's toolchain and validated through flight testing.
Tech Stack: FLYATIVE toolchain, C++, Python, composite rapid prototyping, experimental piloting
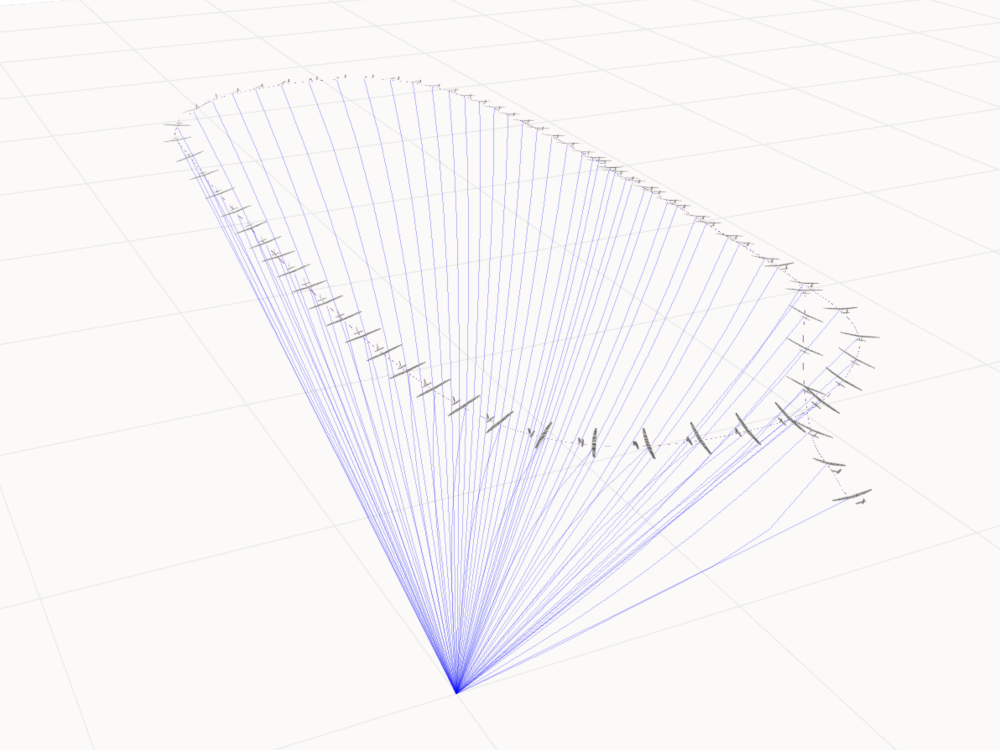
Tethered UAV Orbiting
Tethered Aircraft orbit simulation built from scratch in C++.
- Flexible tether model & aircraft dynamics
- Model based control loops
- Active ground-station tether tension management
Tech Stack: C++, Model based Control
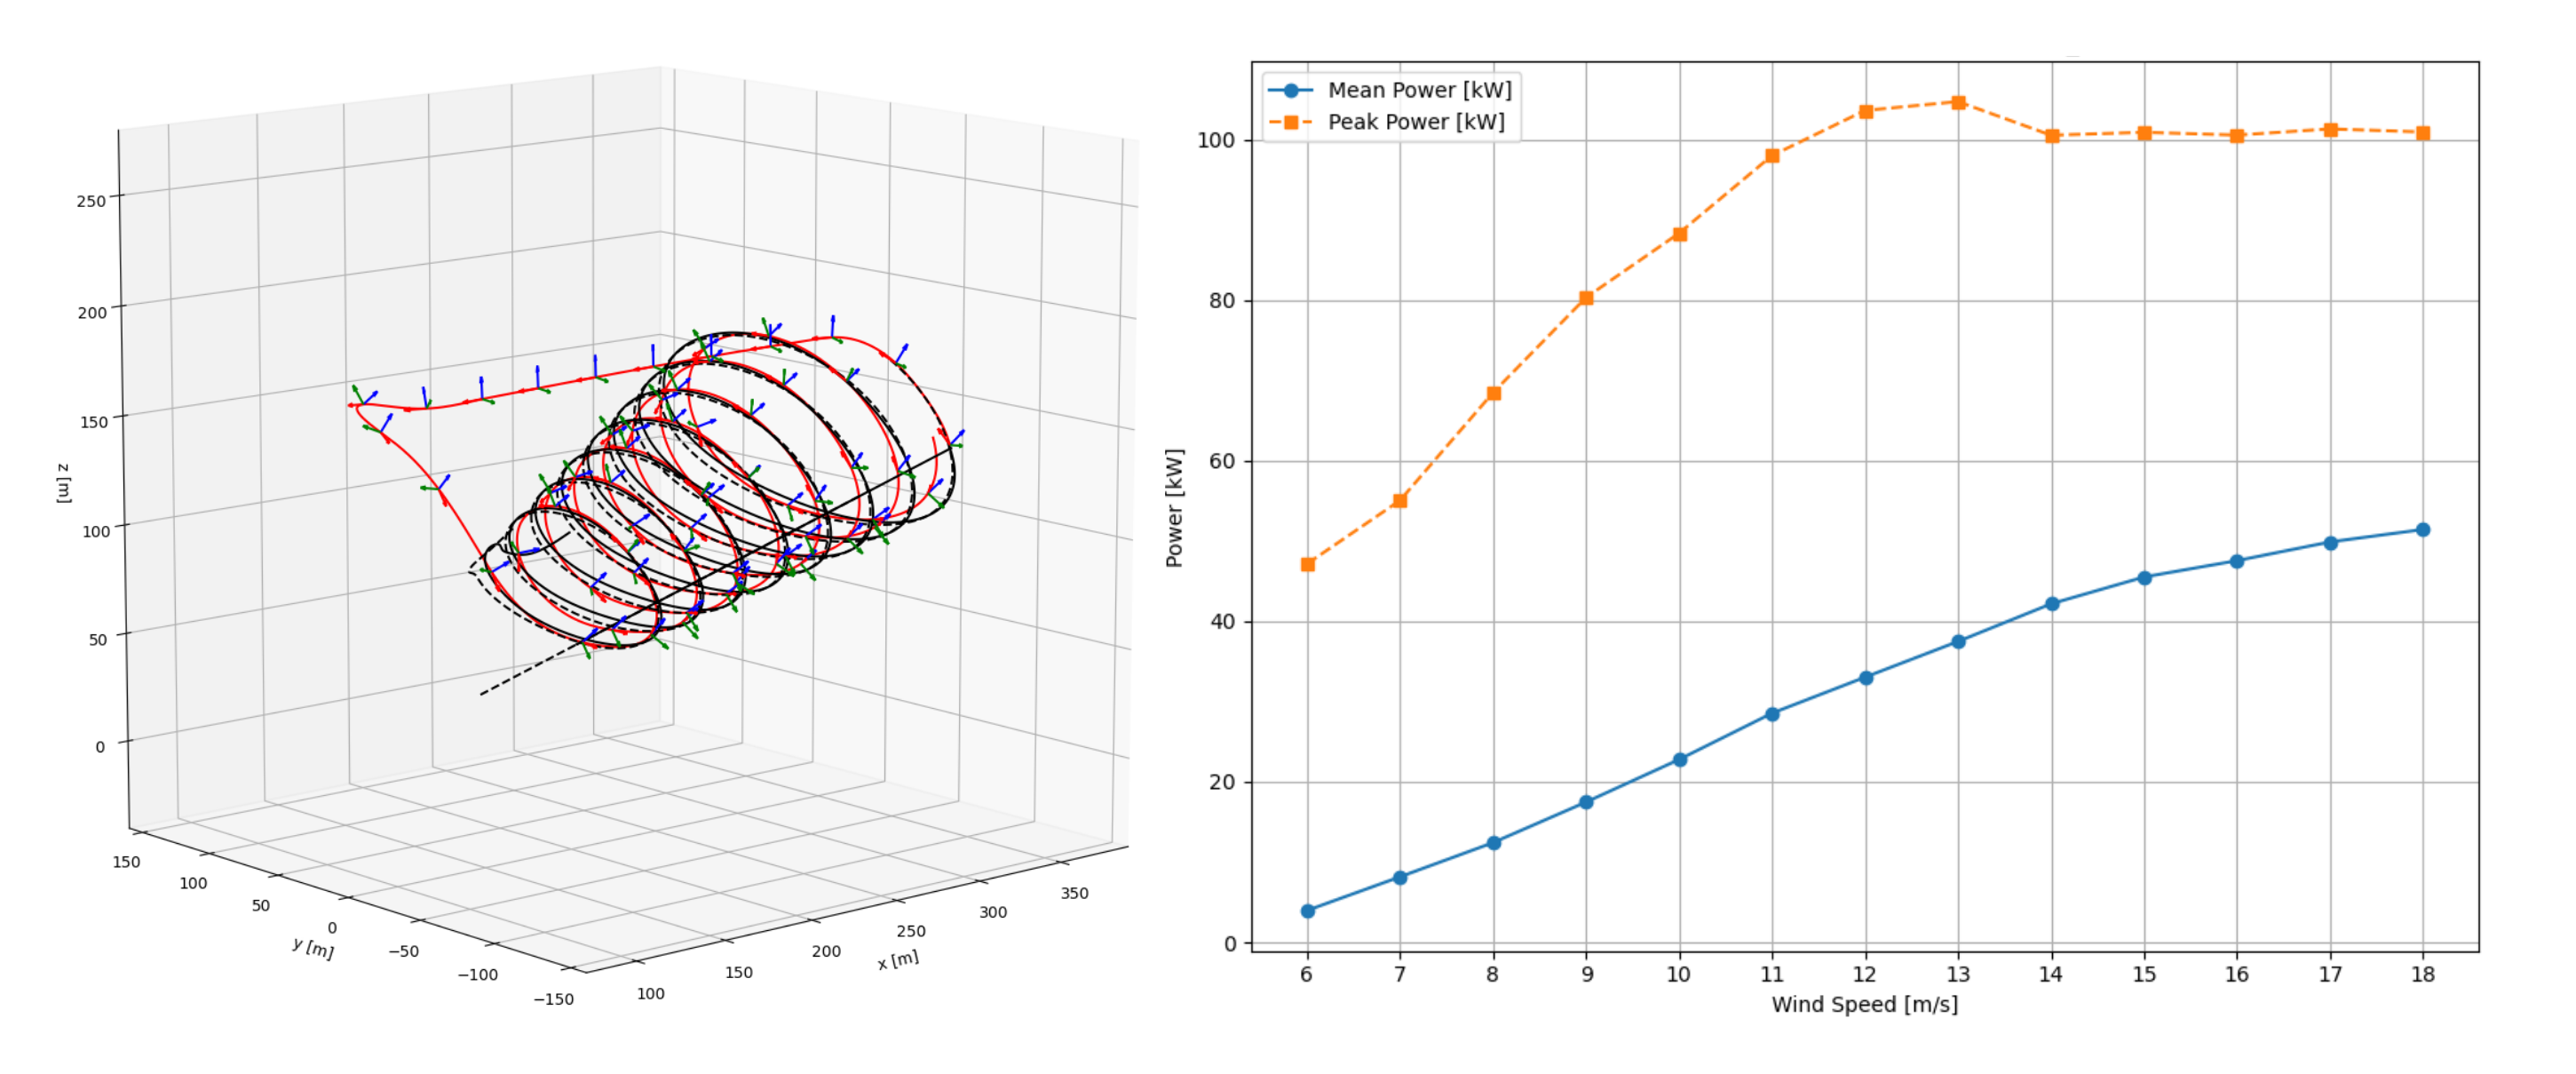
Optimization Engine for Kitepower
Trajectory Optimization for Kitepower
- Optimization of flight trajectories for maximum power generation
- Model-based control & flight dynamics model
- Constraint trajectory optimization
Tech Stack: C++, Nonlinear Constrained Optimization
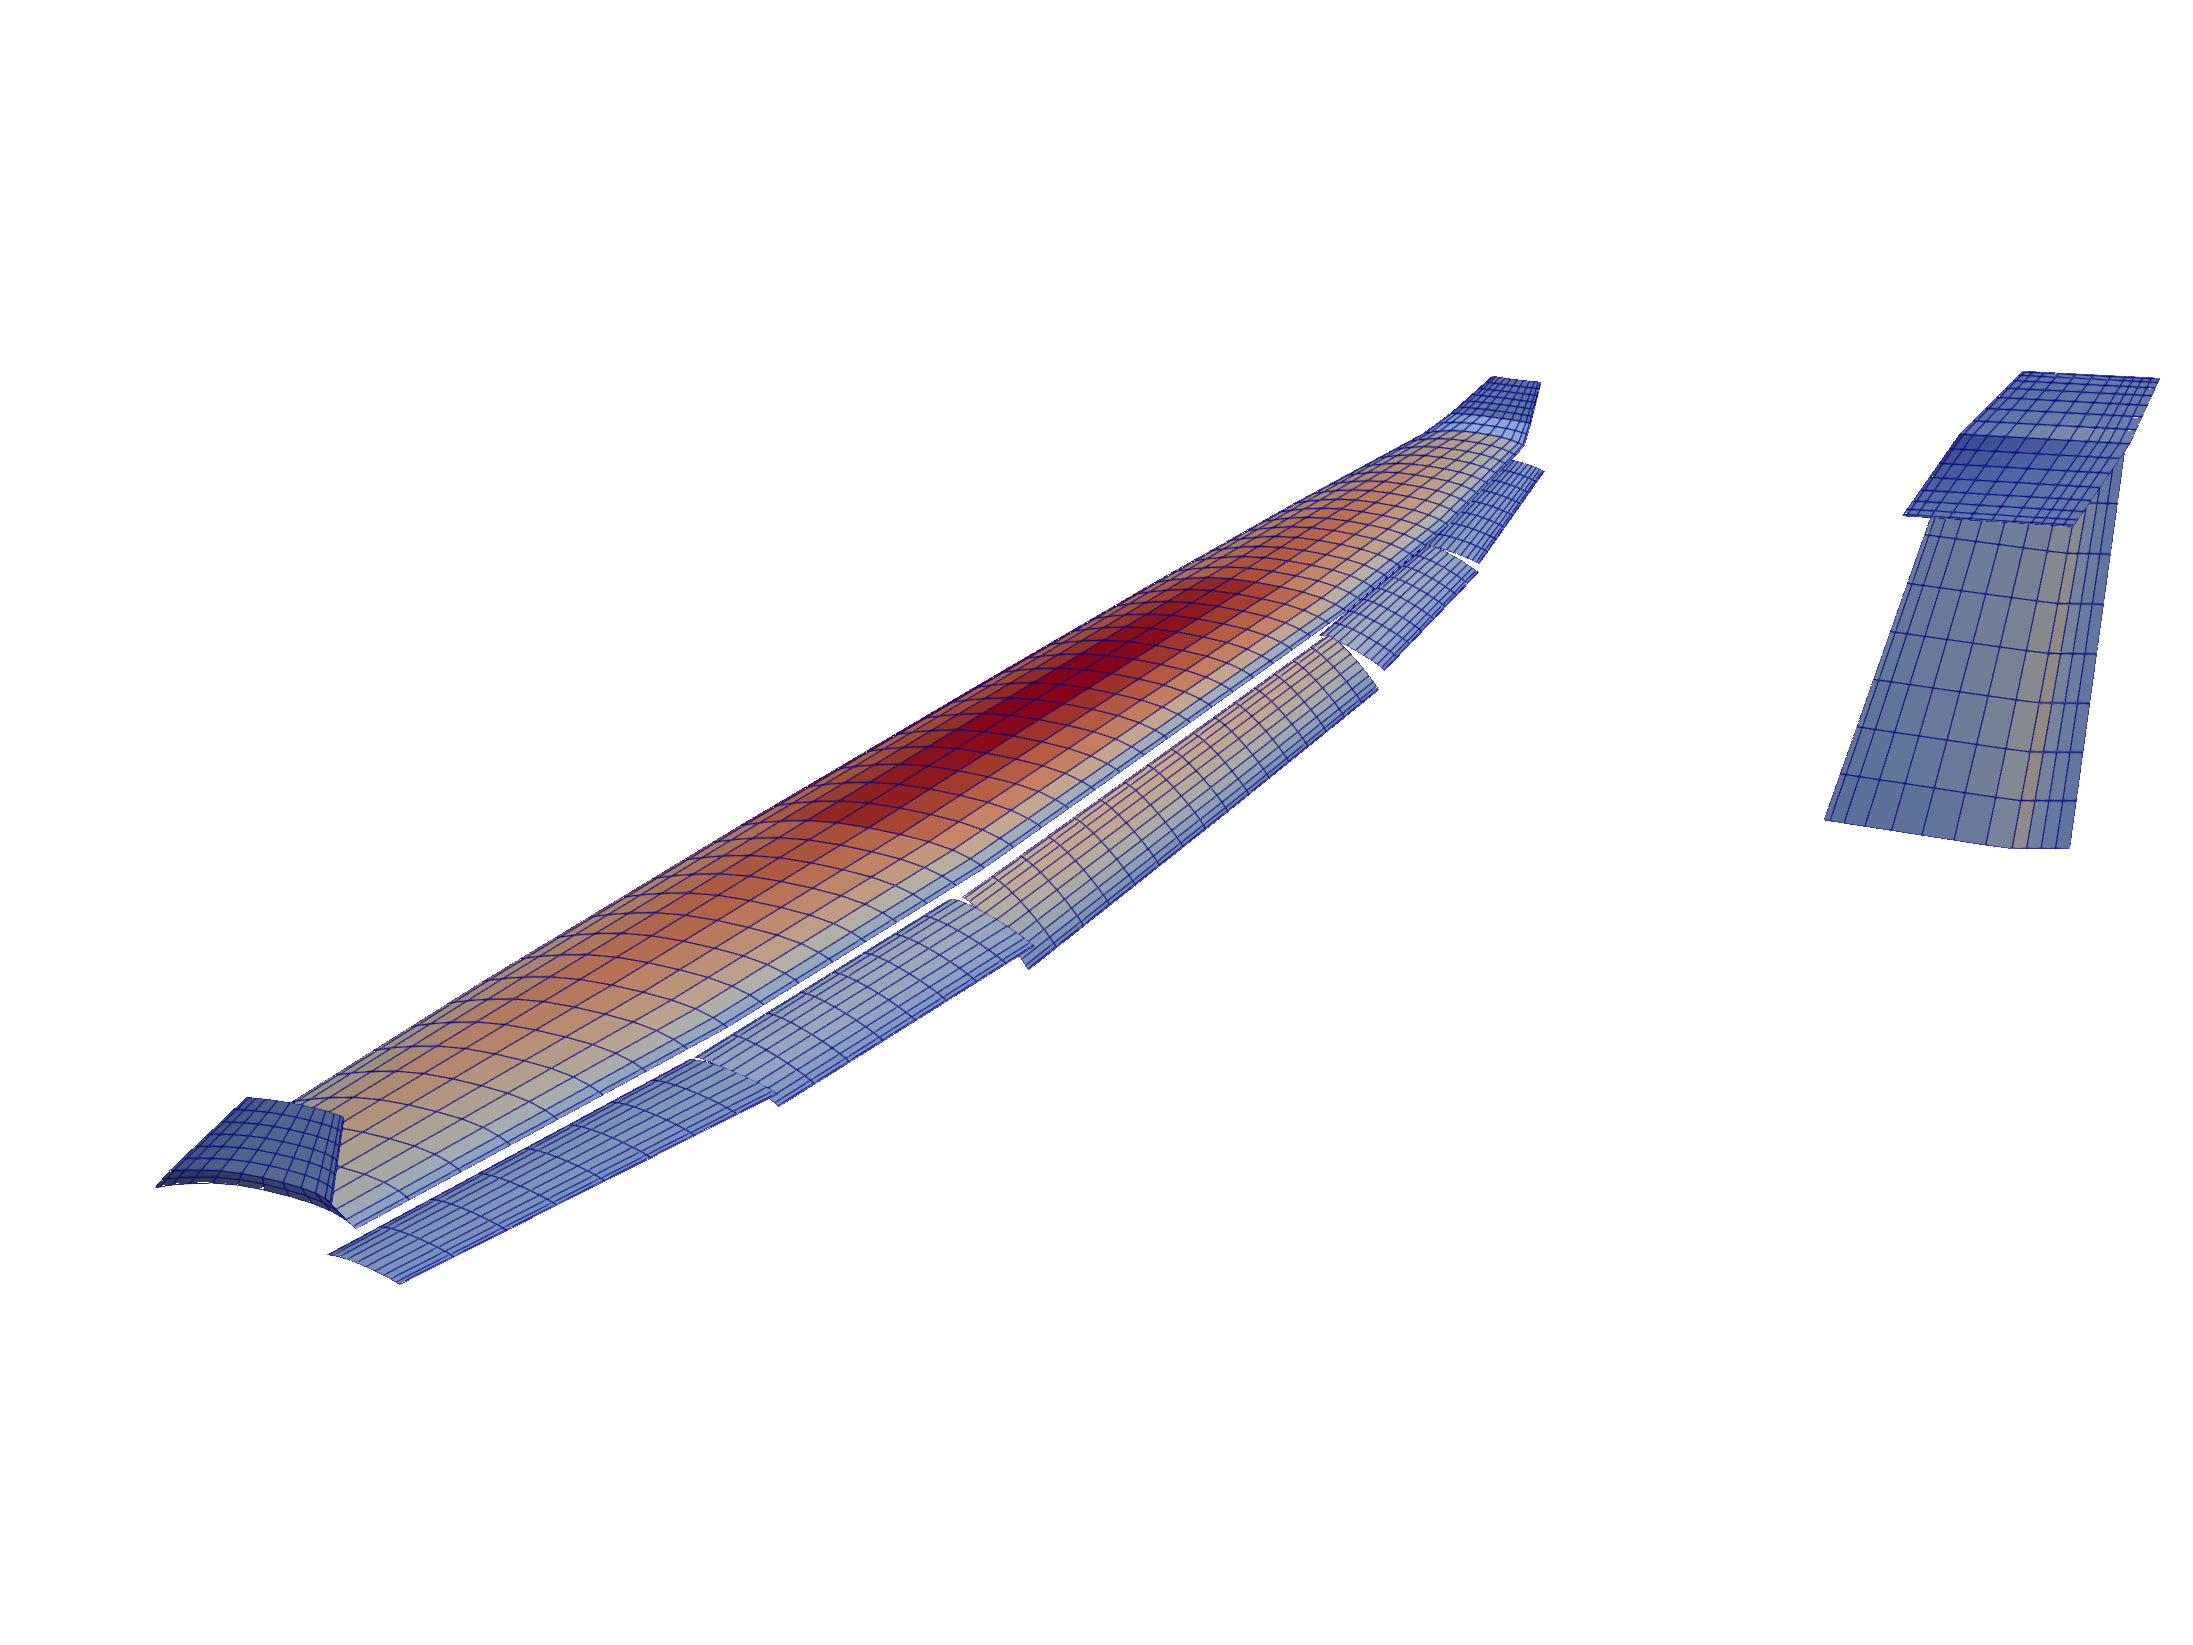
Development of Aerodynamic Toolchain VLMNLLT with Wake Rollup for Multi-Element Airfoils
Developed a nonlinear VLM/NLLT solver with wake roll-up for multi-element airfoils, including wing design and optimization routines for multi-flap wings. Fully integrated into the real-time simulation toolchain.
Tech Stack: C++, Python, numerics, algorithms, mesh generation
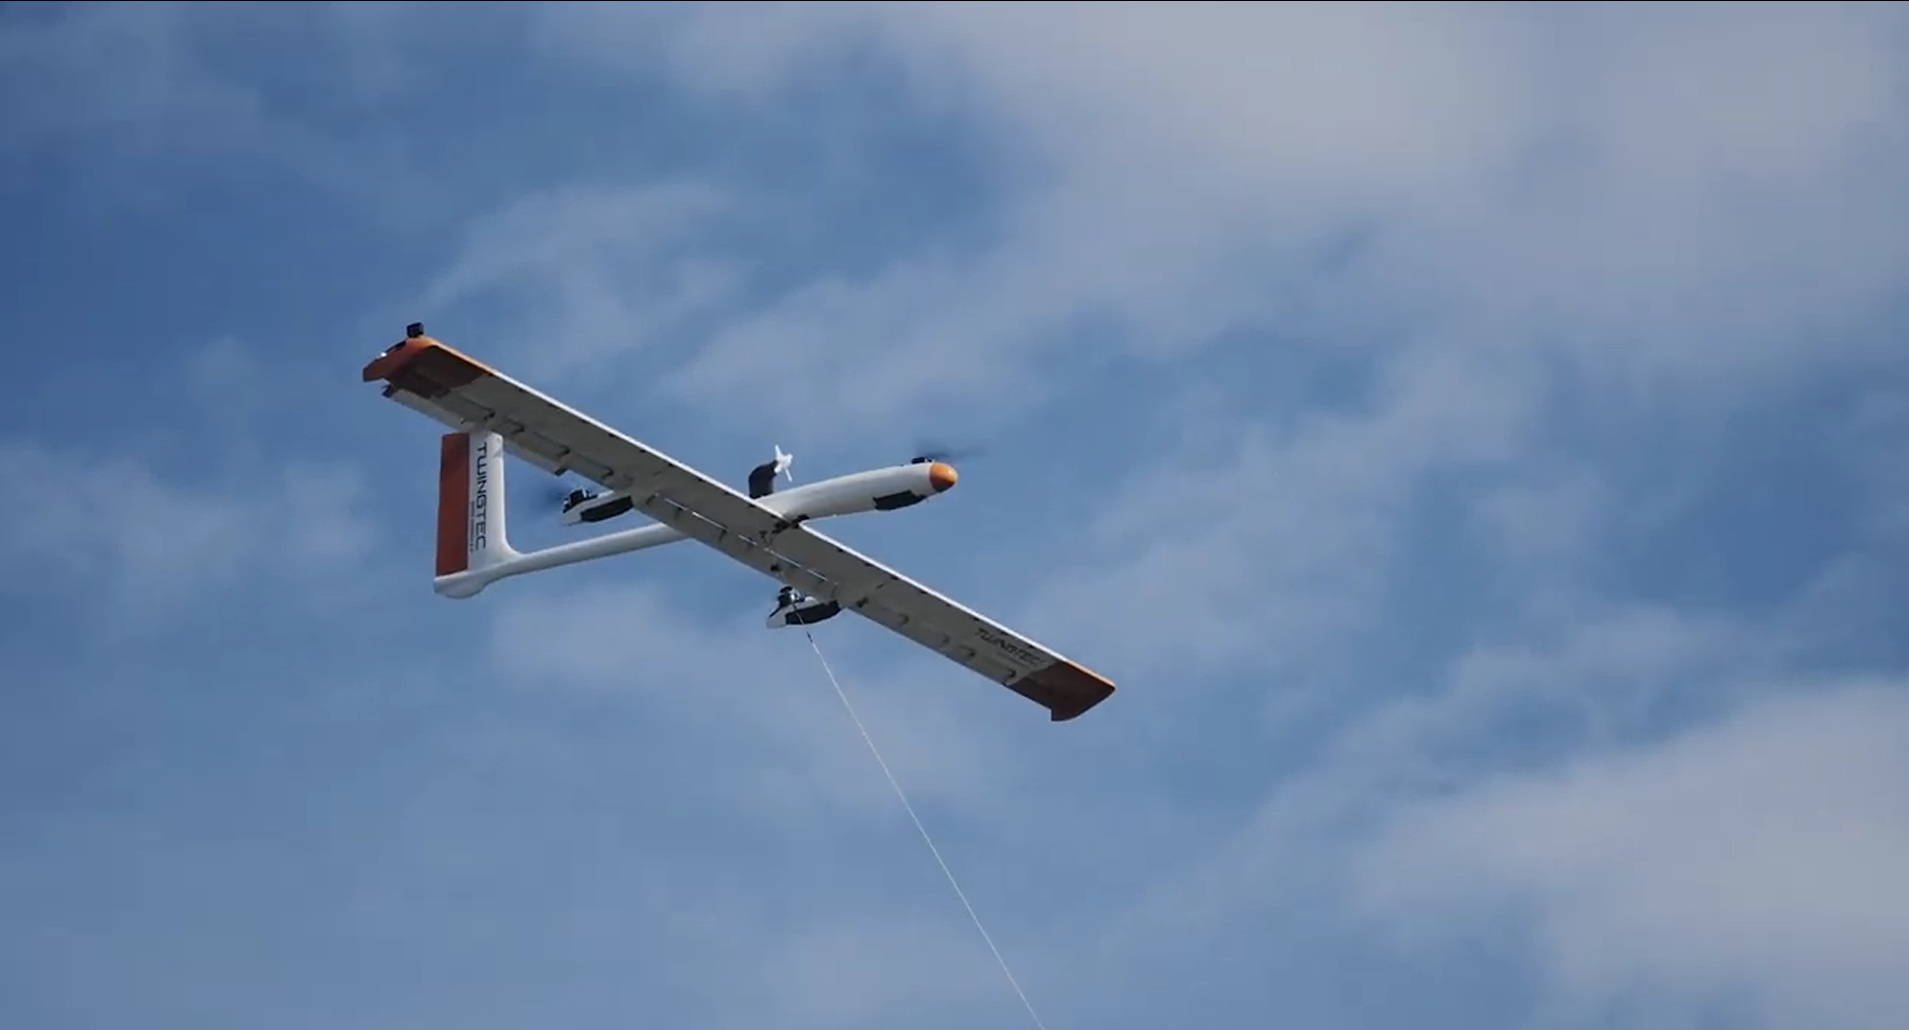
Autonomous AWE eVTOL Platform
Over 30 flight vehicles designed, built, and tested from early prototypes to fully autonomous eVTOL operation. Complete toolchain combining flexible tether models, rigid-body dynamics, real-time aerodynamic models, rotor dynamics, and guidance/control.
Tech Stack: C++, Python, GNC, HIL/SITL, MPC/LQR/PID
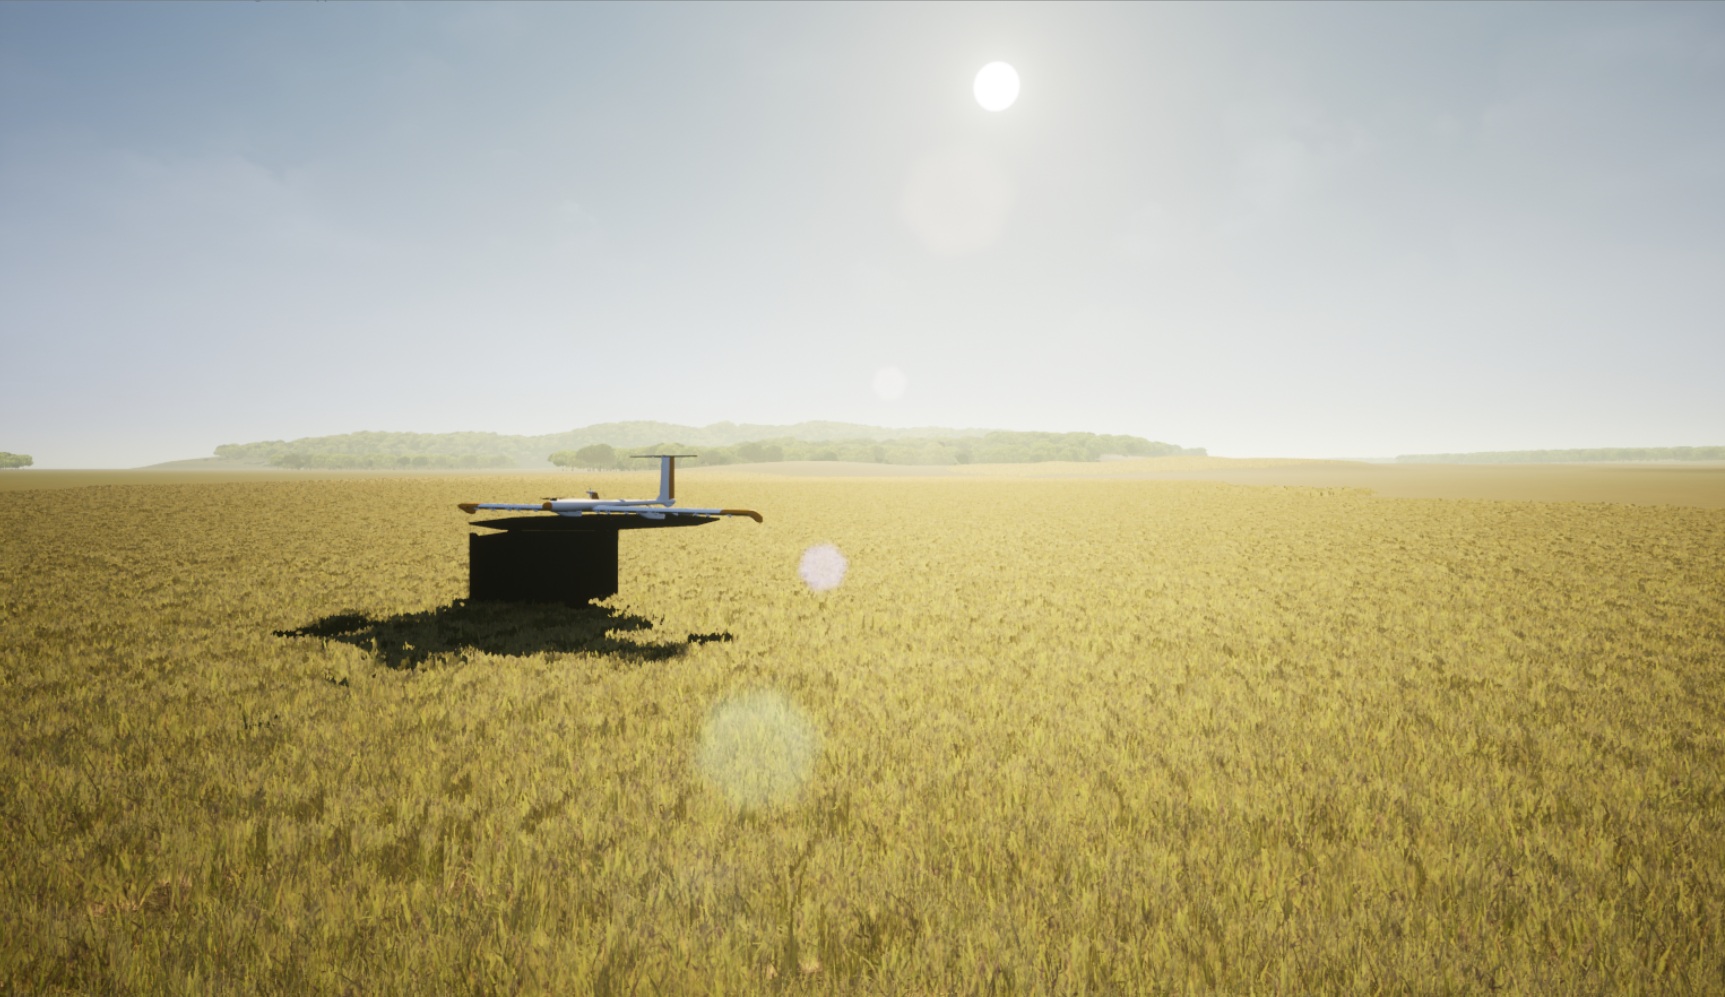
AWE VTOL Flight Simulator for Tethered Aircraft
Development of a realistic flight simulator for autonomous eVTOL AWE systems, integrated with HIL/SITL environments for pilot training.
Tech Stack: C++, Python, Unreal Engine
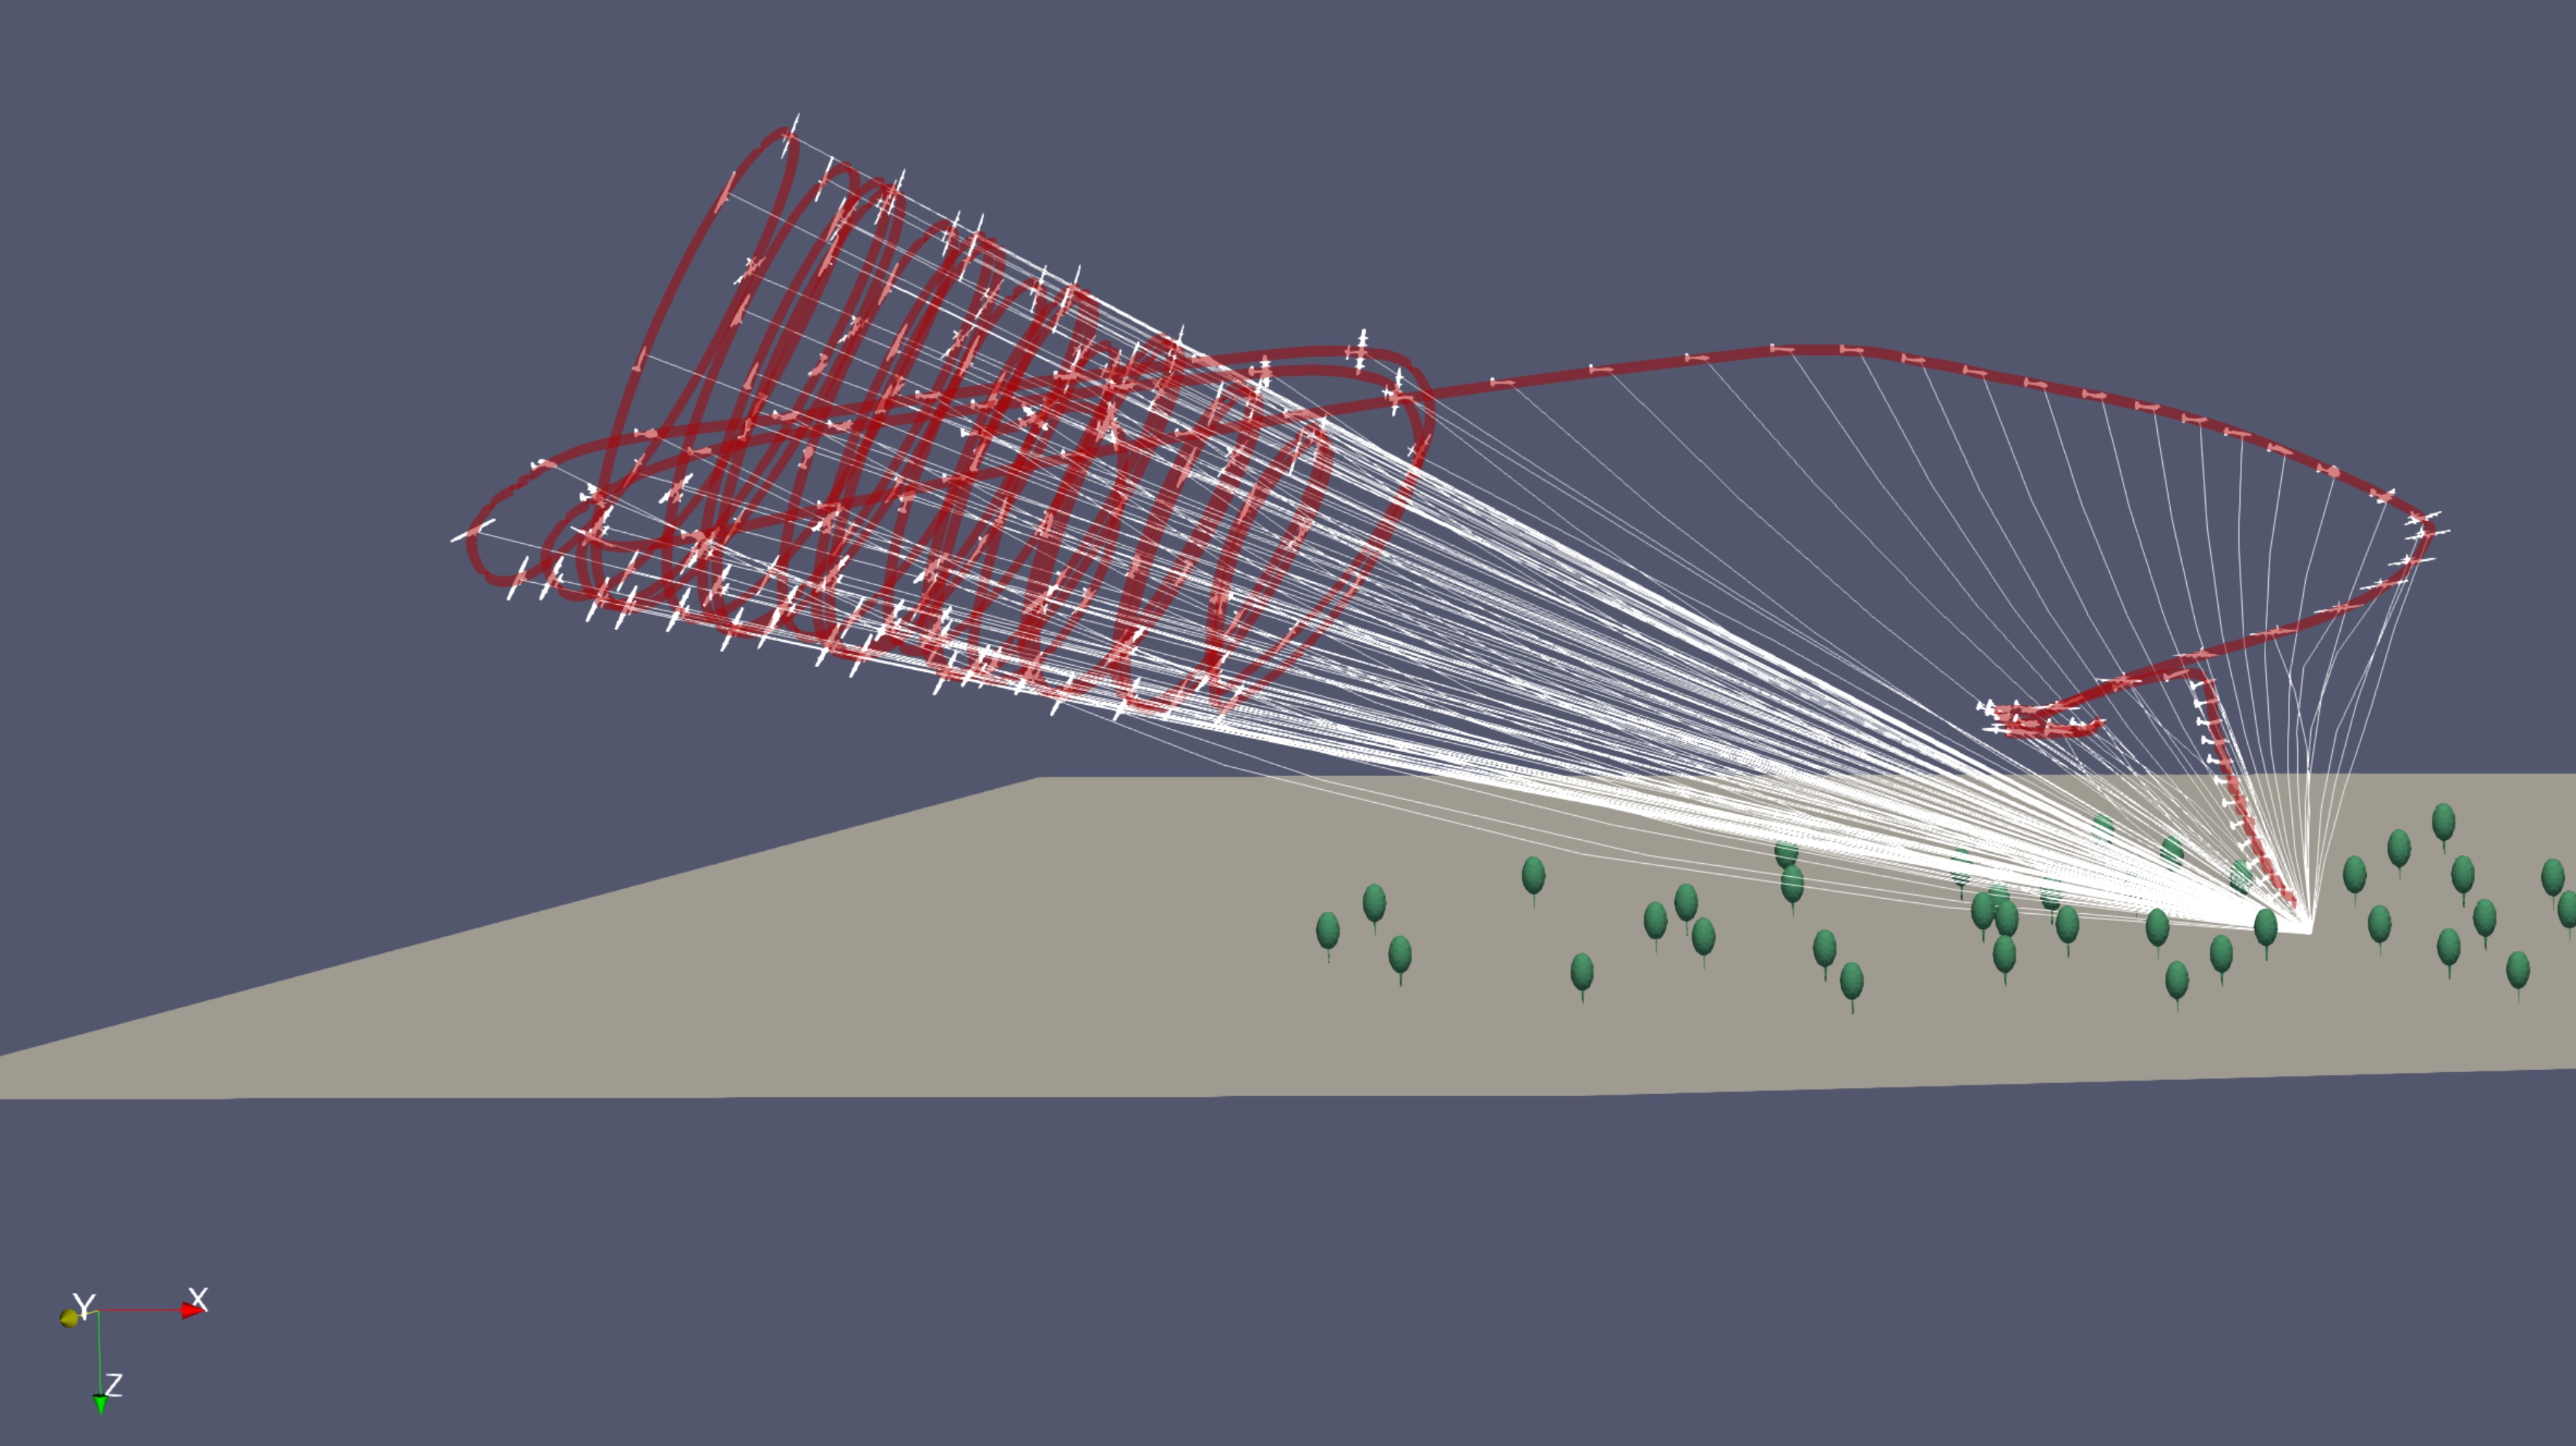
AWE GNC & Simulation Toolchain
Development of the GNC stack and fast simulation toolchain for autonomous Airborne Wind Energy systems. Including VTOL launch and landing.
Tech Stack: C++, Python
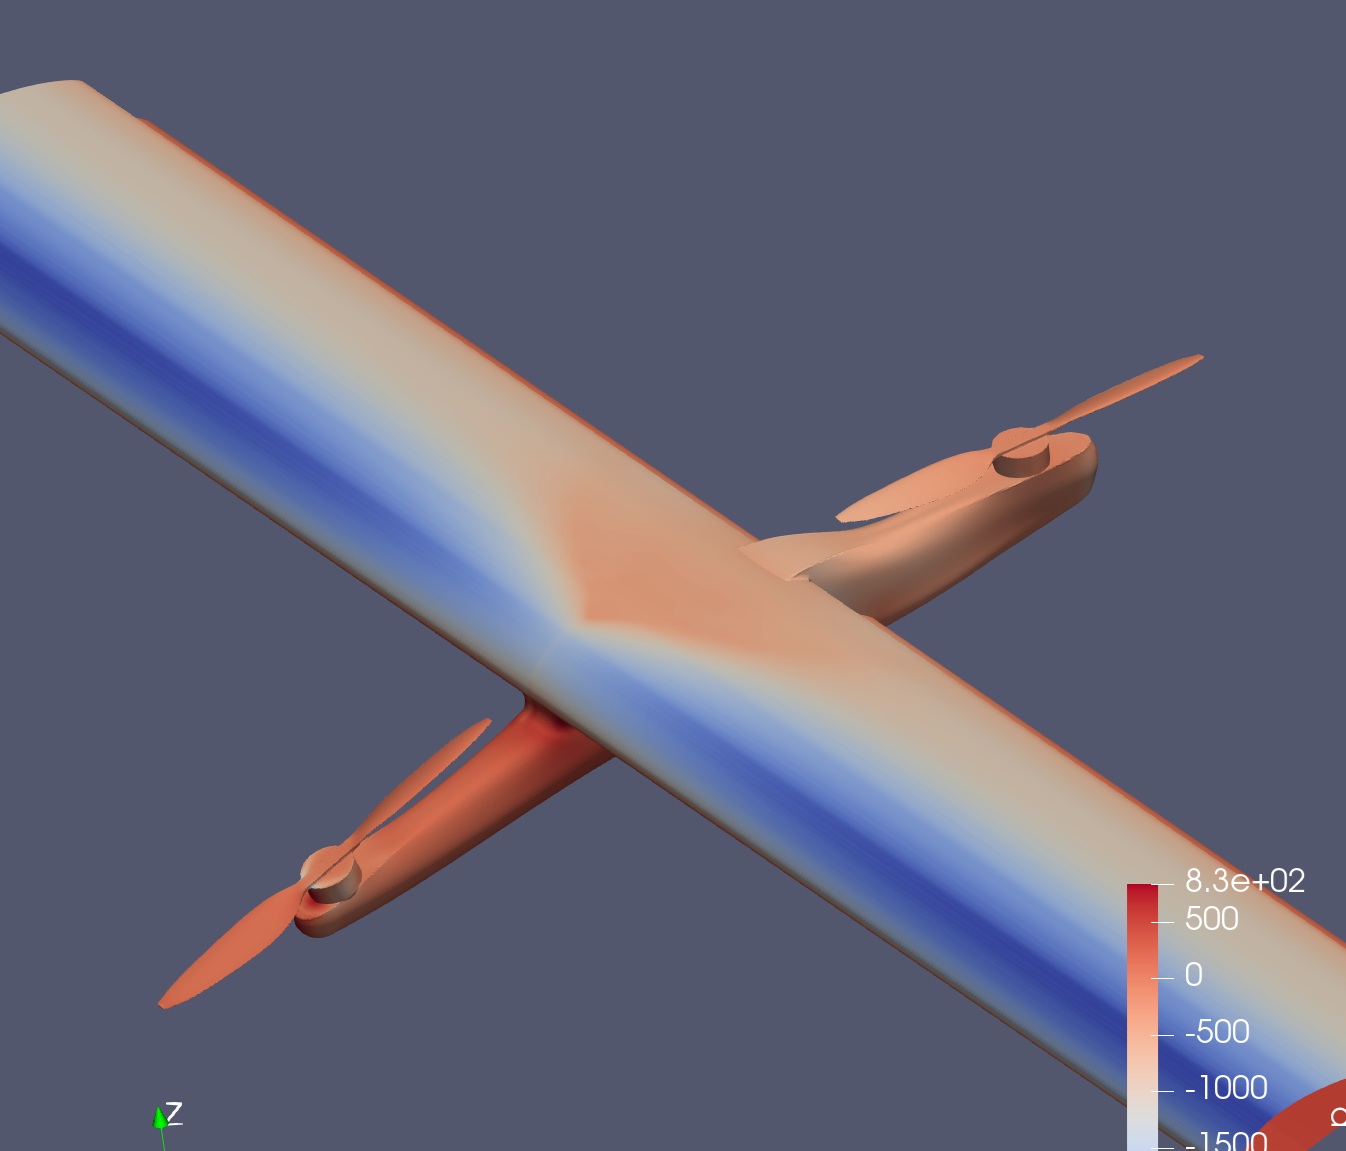
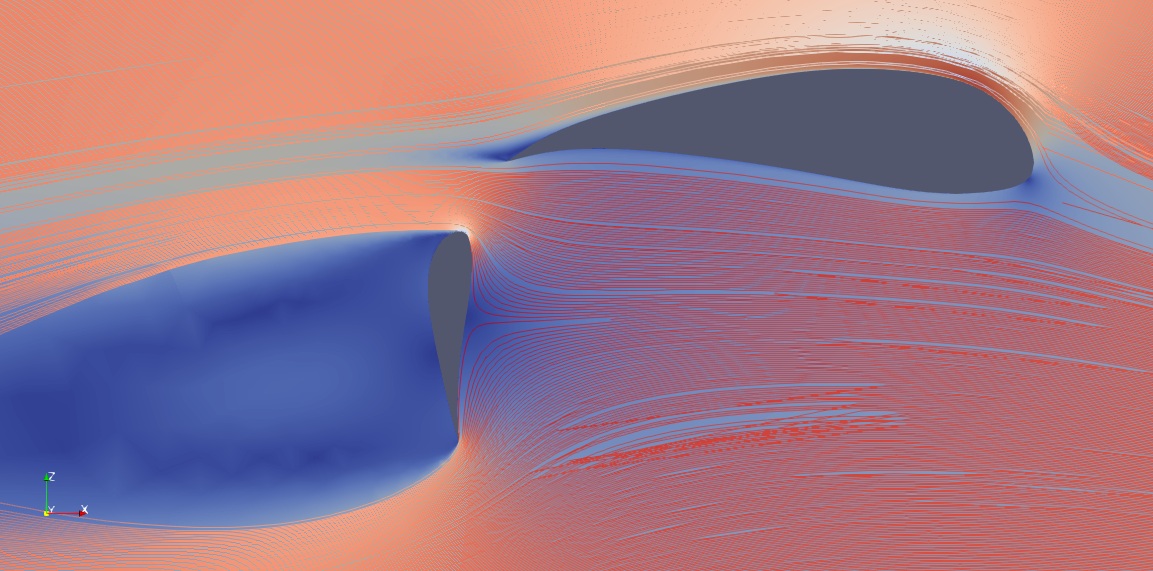
CFD: Multi-Element Airfoil Design and Rotor-Wing Interaction
Studies of non-linear aerodynamic effects of high lift multielement airfoils and rotor-wing interaction for autonomous eVTOL AWE systems.
Tech Stack: OpenFOAM, XFOIL, OpenVSP
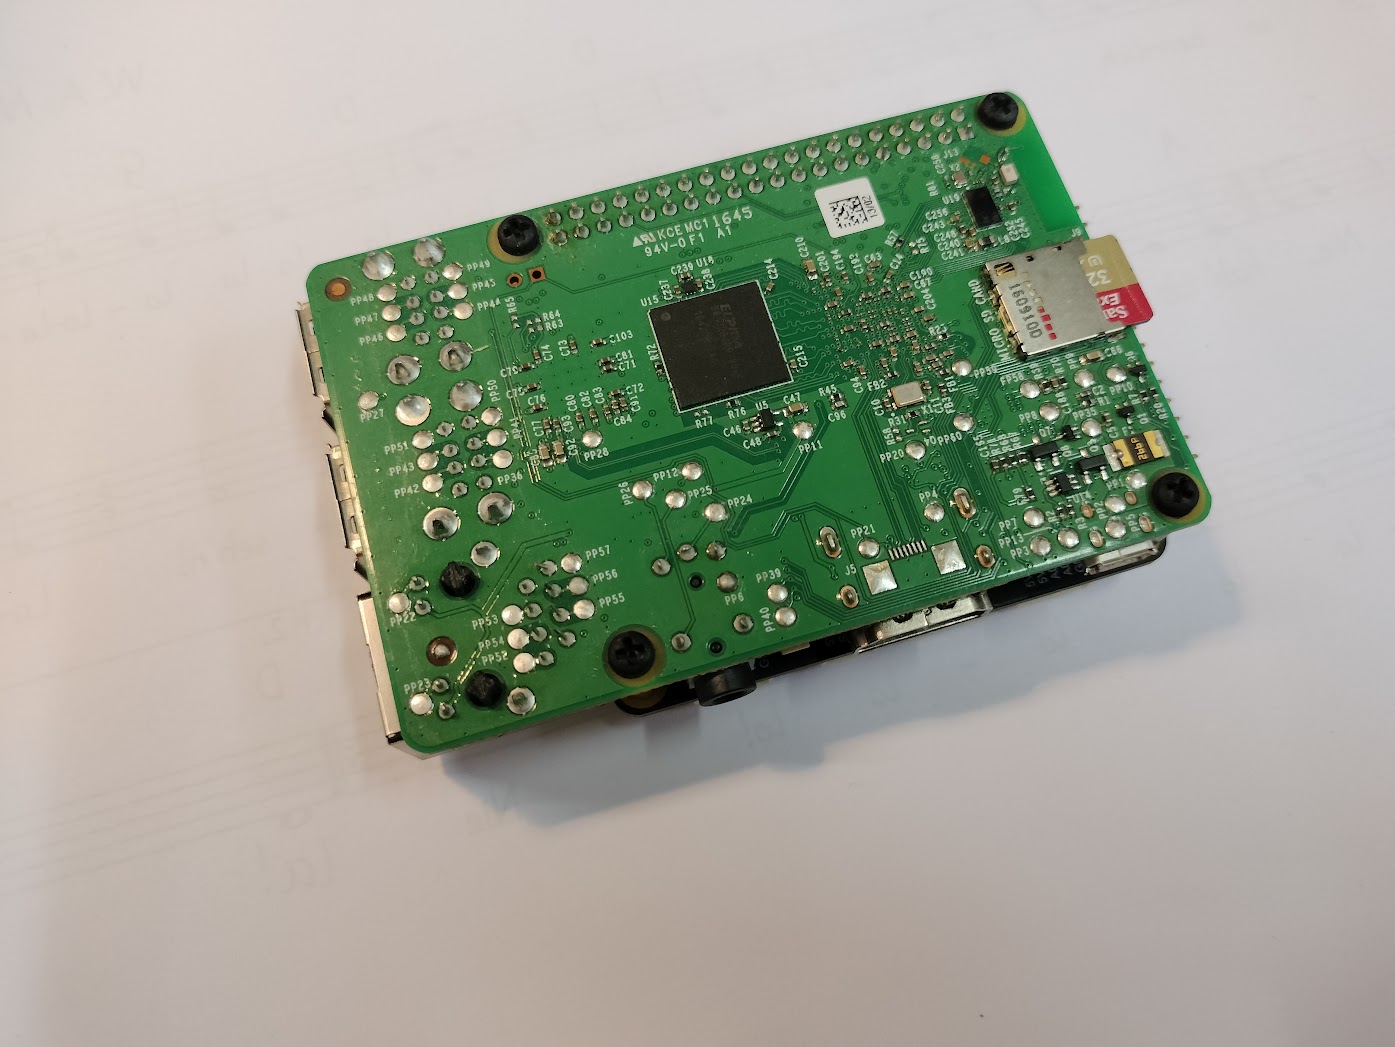
Onboard Flight Software for Autonomous eVTOL AWE Systems
Development of complete onboard flight software for autonomous eVTOL AWE systems, including: sensor fusion, state estimation, guidance, navigation, control algorithms, state machine, and communication protocols. Developed dedicated robot middleware for real-time communication and logging, inspection and debugging. Tested in custom HIL/SITL environments and on real hardware.
Tech Stack: C++, Python, Linux, embedded software engineering
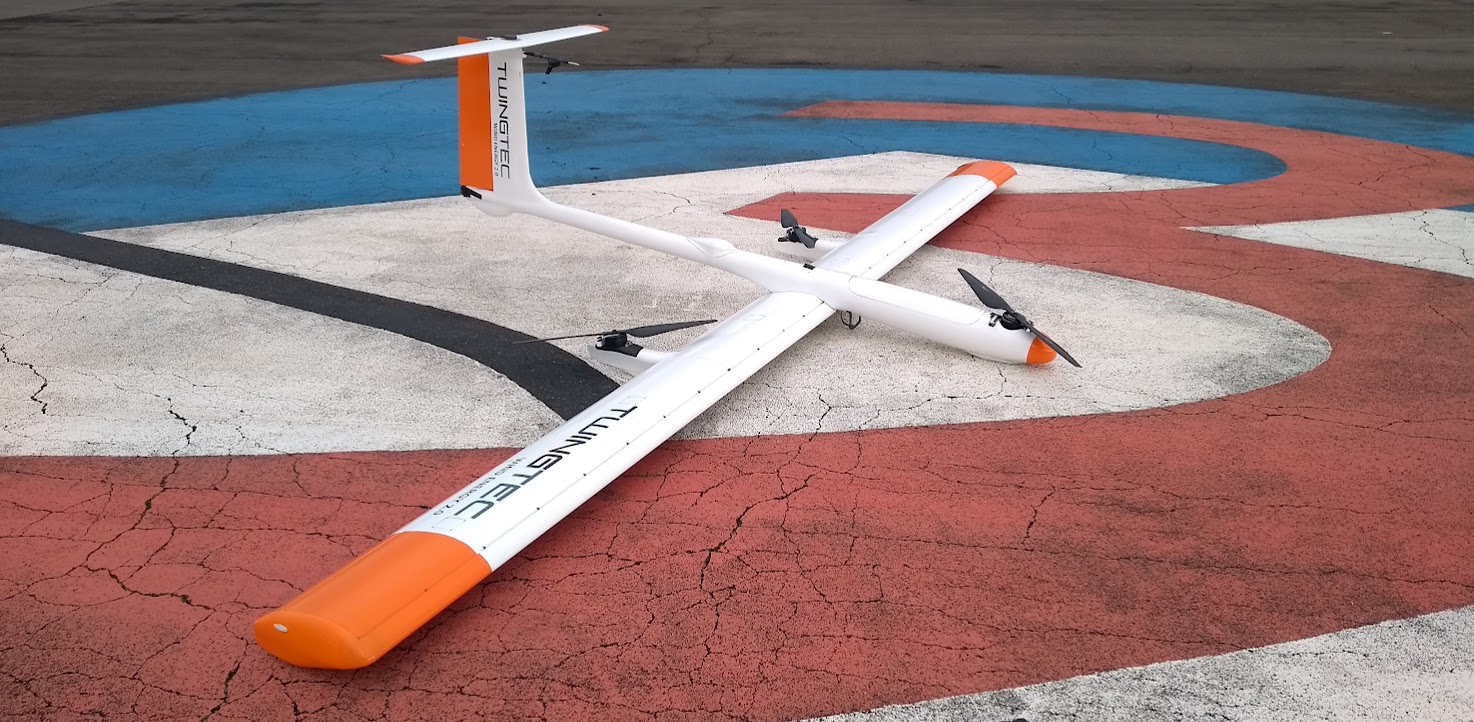
10 kW Pilot System: 5.5m span eVTOL Wind Energy Drone 2021
An in-house pilot system for autonomous wind-energy drones, developed through a hands-on design, build, and flight-test cycle. Test pilot: Flavio Gohl.
Tech Stack: Composite Manufacturing, rapid prototyping, CAD/CAM, Aerospace engineering, test pilot
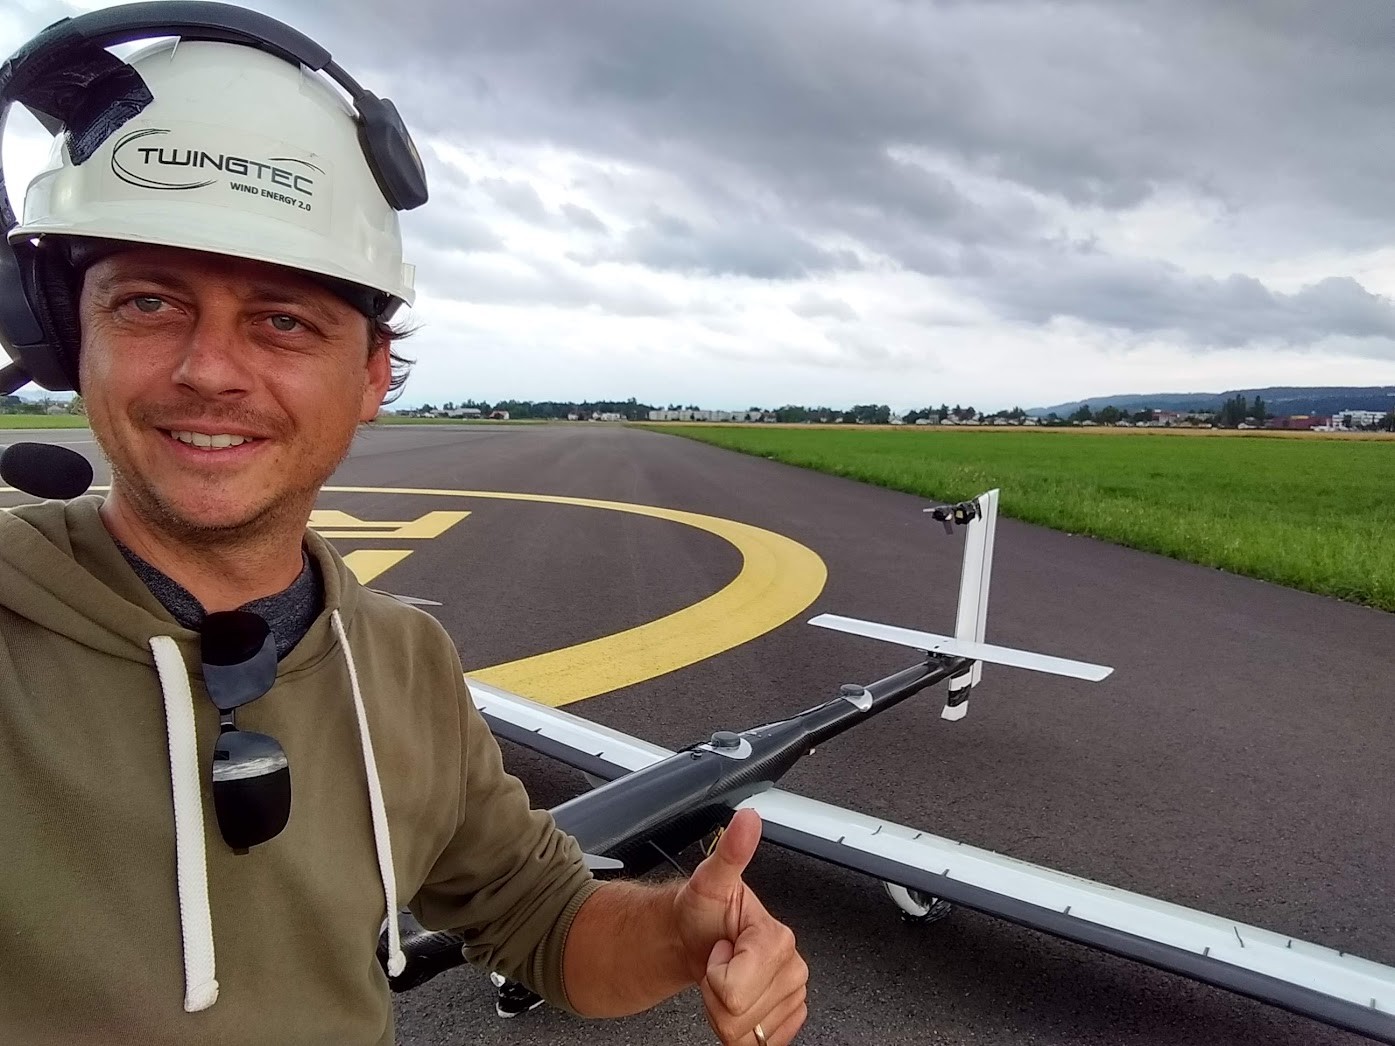
Technology Demonstration prototype 2018
An in-house composite wind-energy drone developed through a hands-on design, build, and flight-test cycle. Technology demonstrator for TwingTec's wind-energy drone. Test pilot: Flavio Gohl.
Tech Stack: Early-stage conceptual design, composite manufacturing, rapid prototyping, CAD/CAM, aerospace engineering, and flight testing
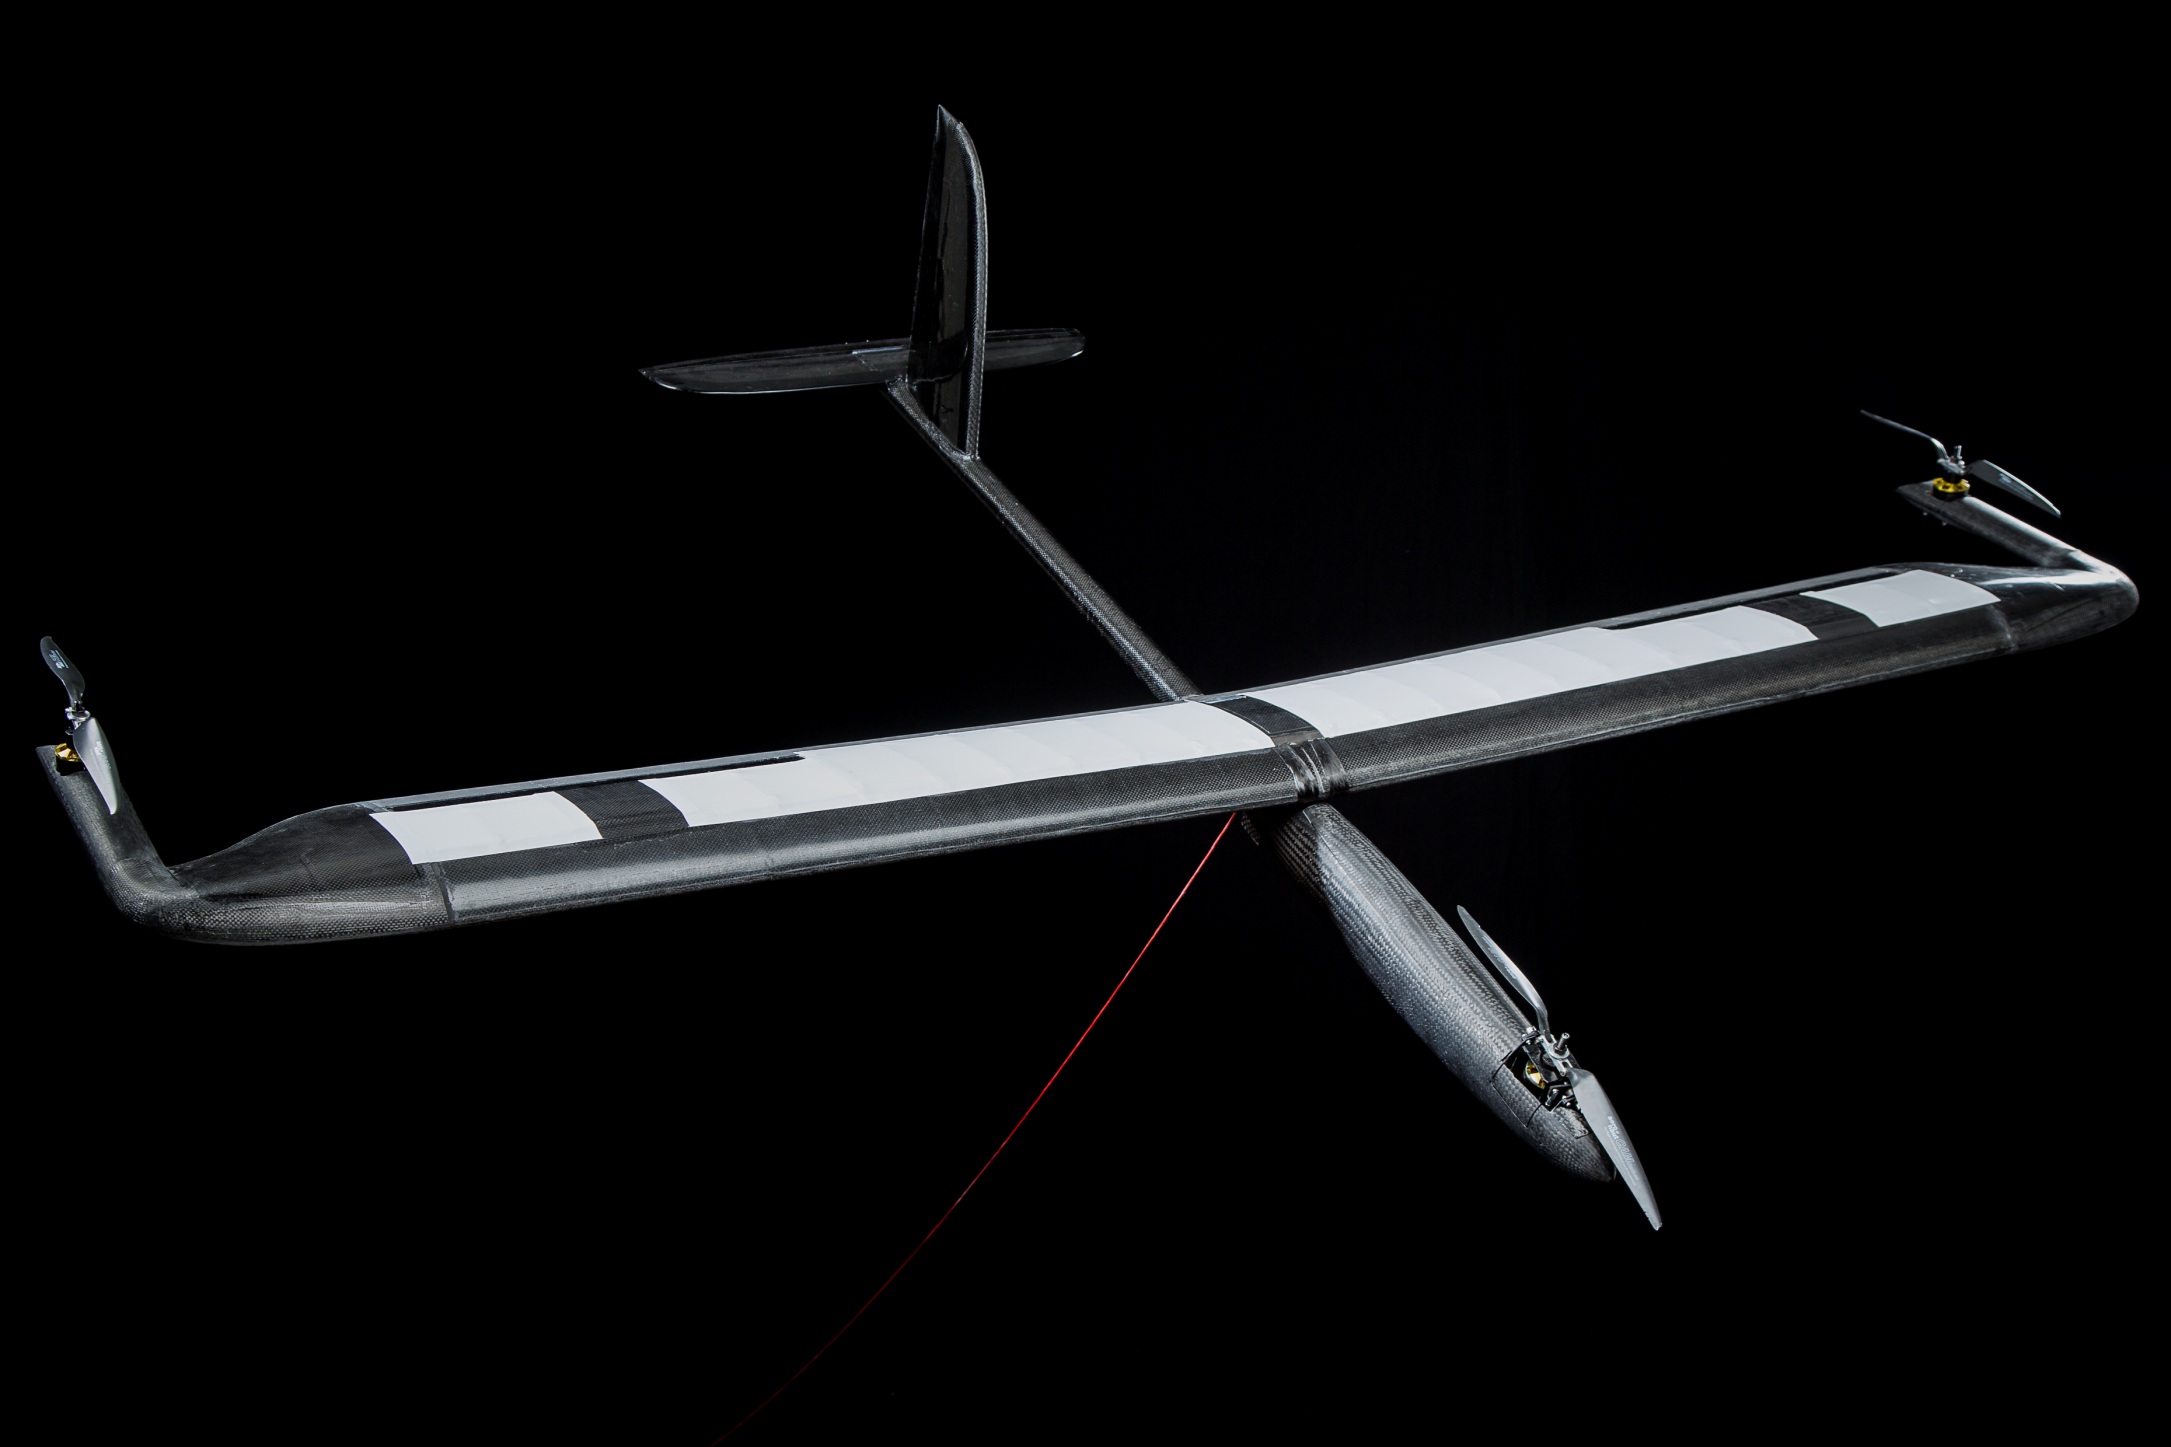
Prototype eVTOL AWE
Inhouse manufactured eVTOL ultralight for kitepower applications. Fully carbon Fuselage and canopy covered wing.
Tech Stack: Ultralight eVtol for AWE
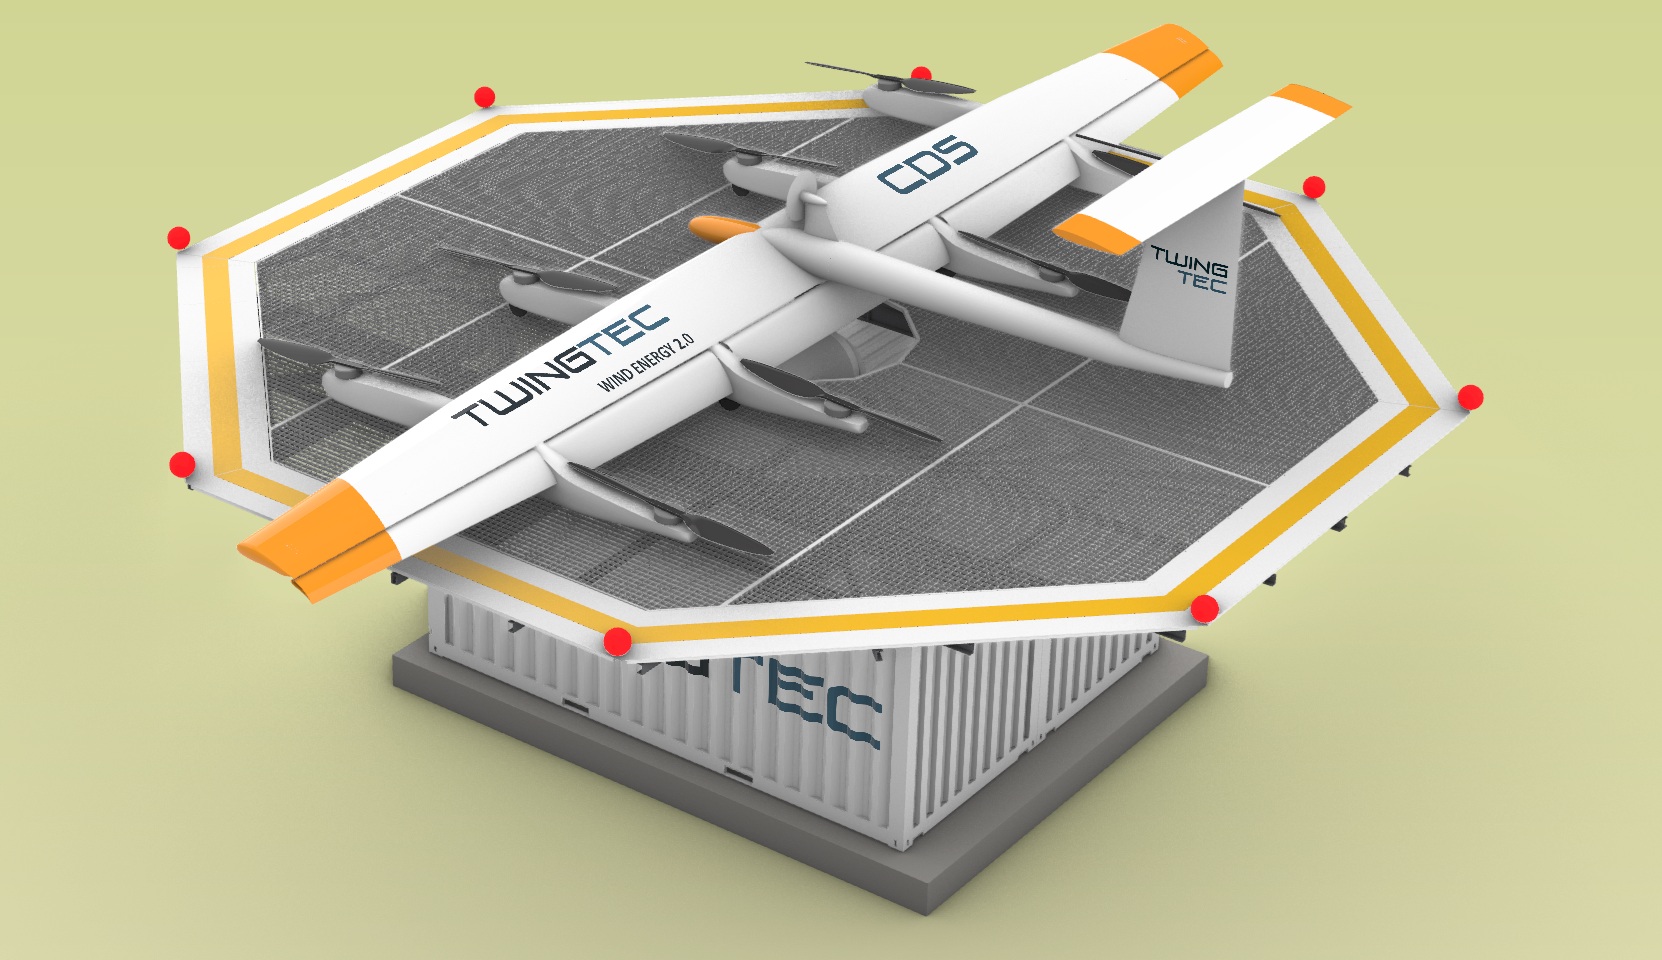
Conceptual Design of a 1 MW eVTOL Wind Energy Drone
Conceptual design and analysis of a 1 MW eVTOL wind energy drone for autonomous power generation.
Tech Stack: Aerospace Engineering, CAD, Project Management
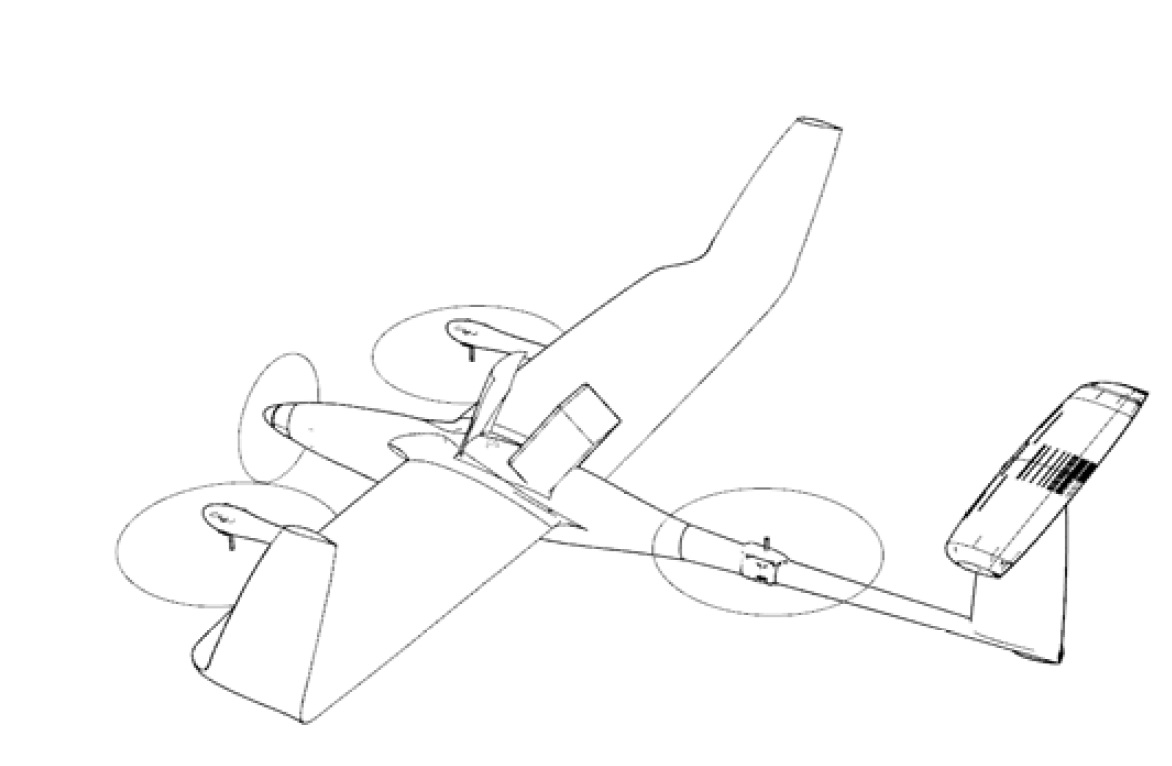
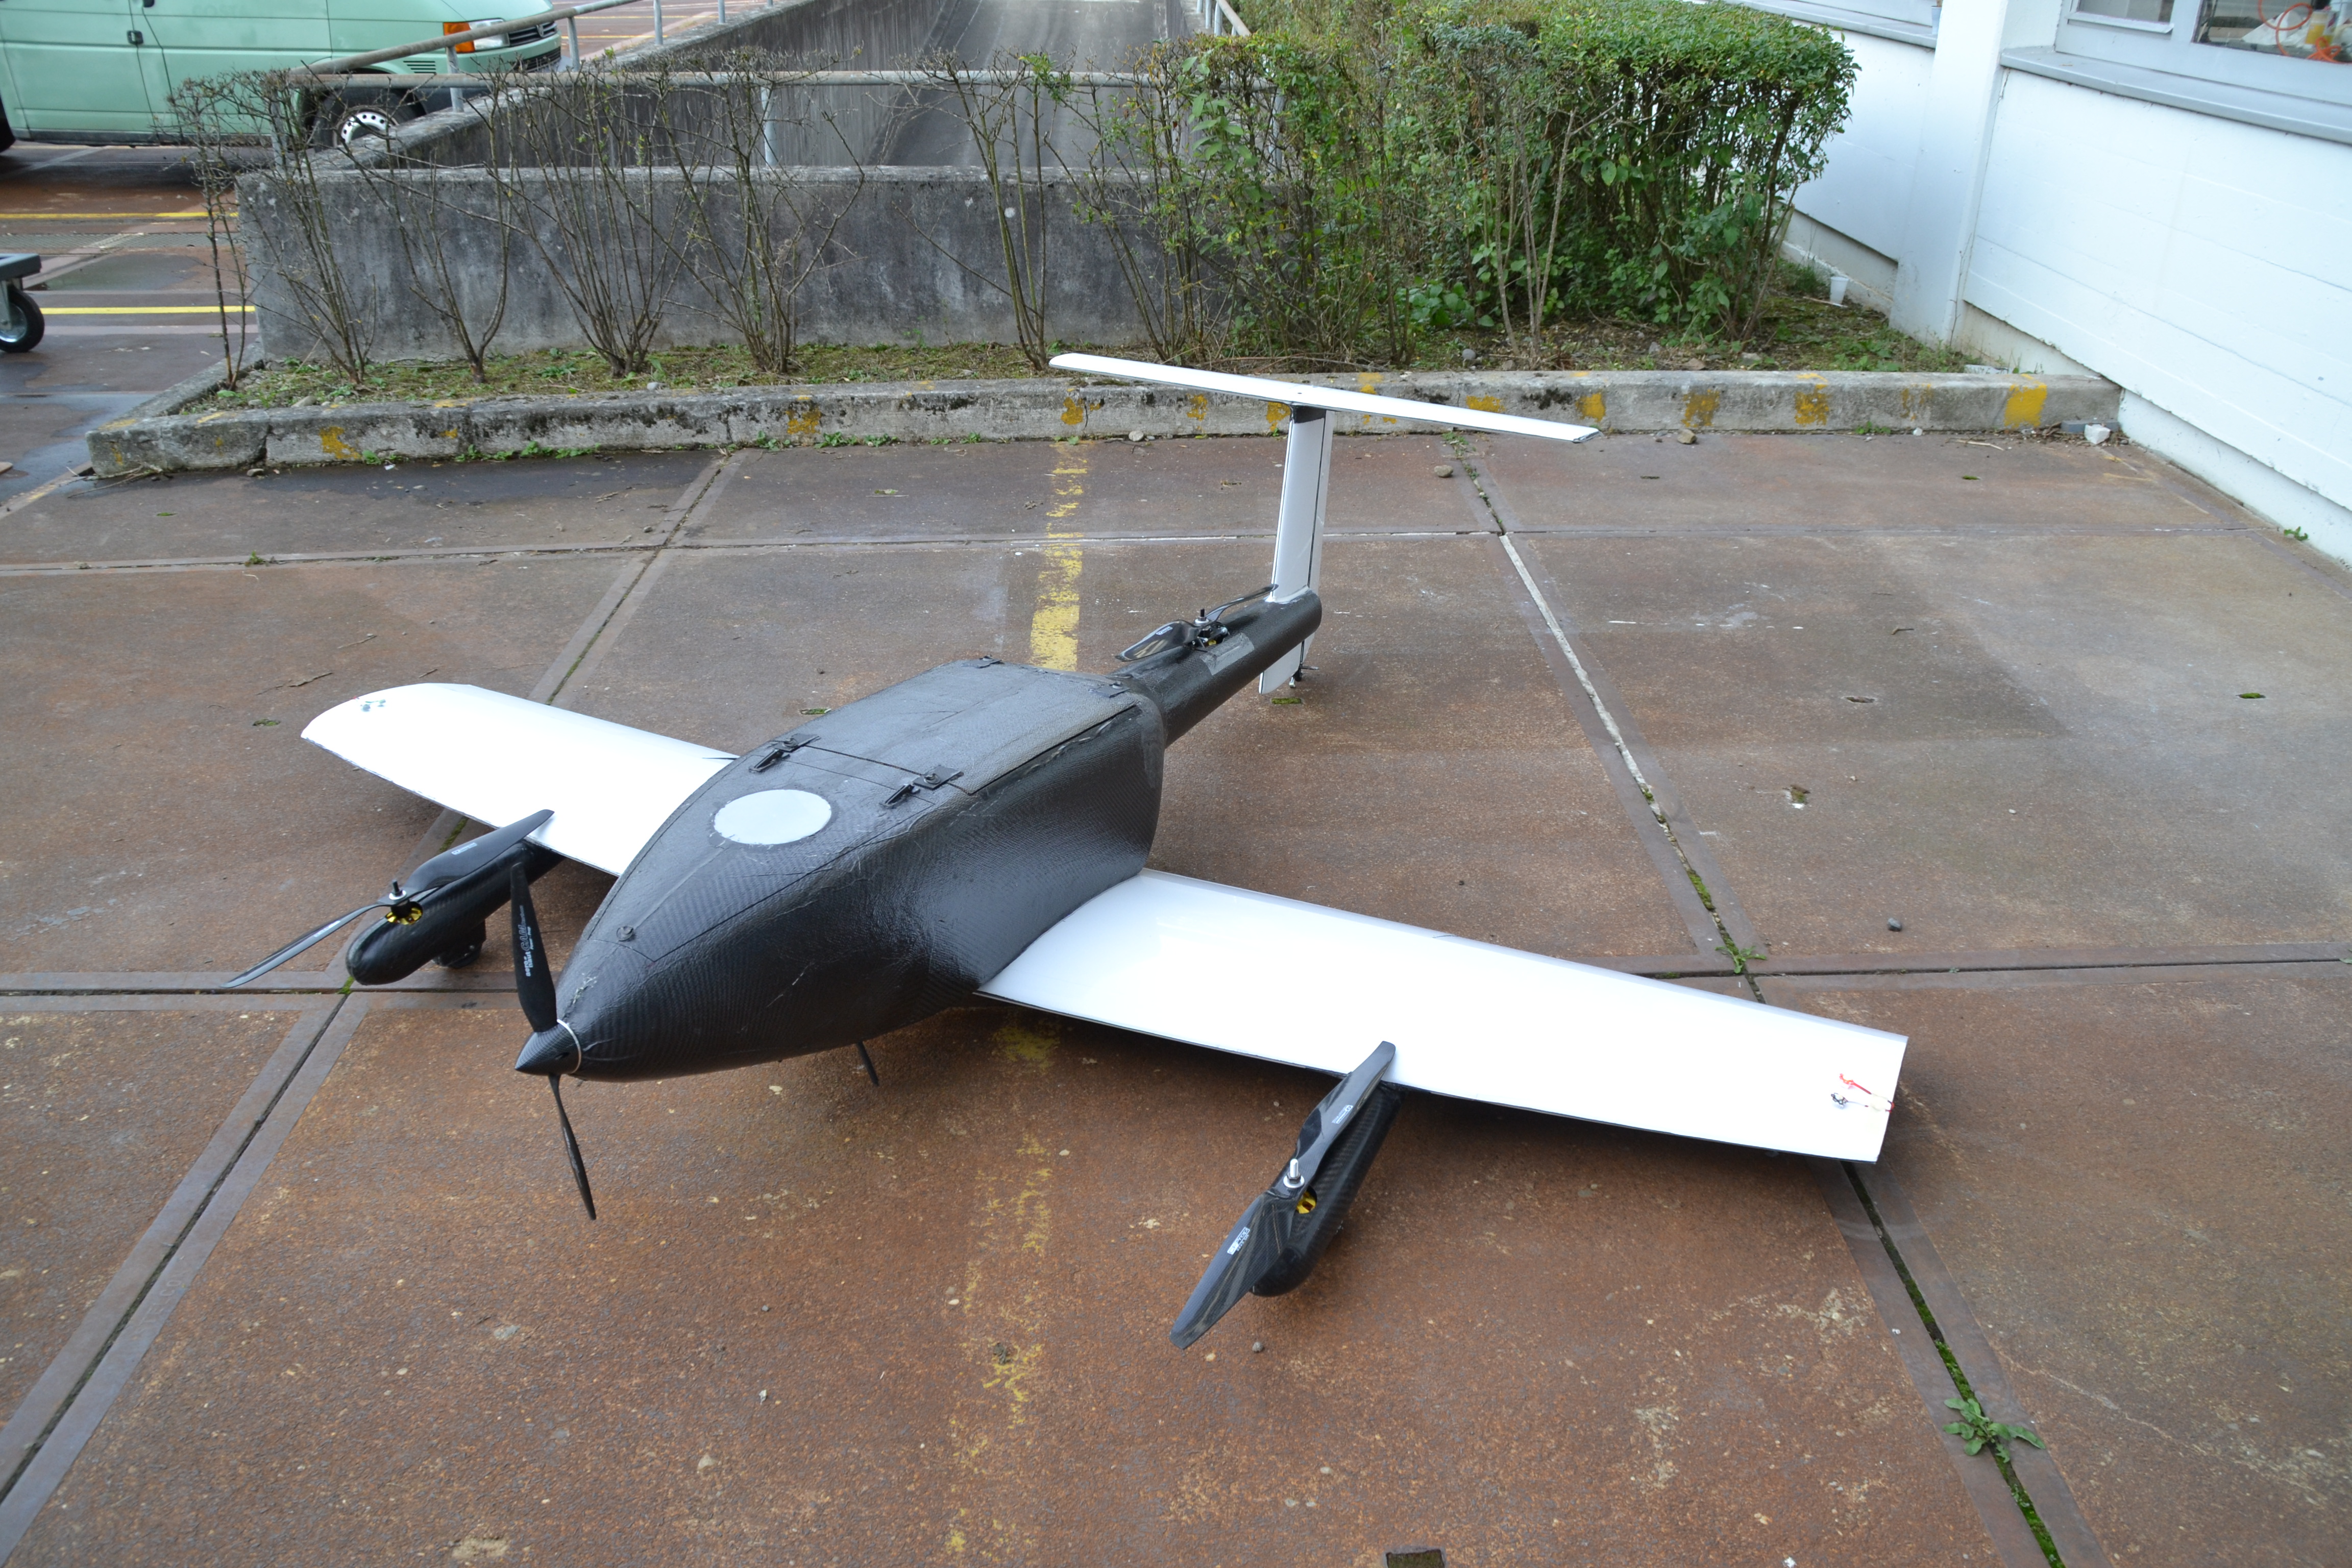
eVTOL Delivery Drone 2017
Design and development of an eVTOL drone for package delivery applications. Prototype developed in-house. Flight testing by Test pilot: Flavio Gohl.
Tech Stack: Aerospace Engineering, CAD, Project Management